ROH-AP001
Sense Force. Control Precisely.
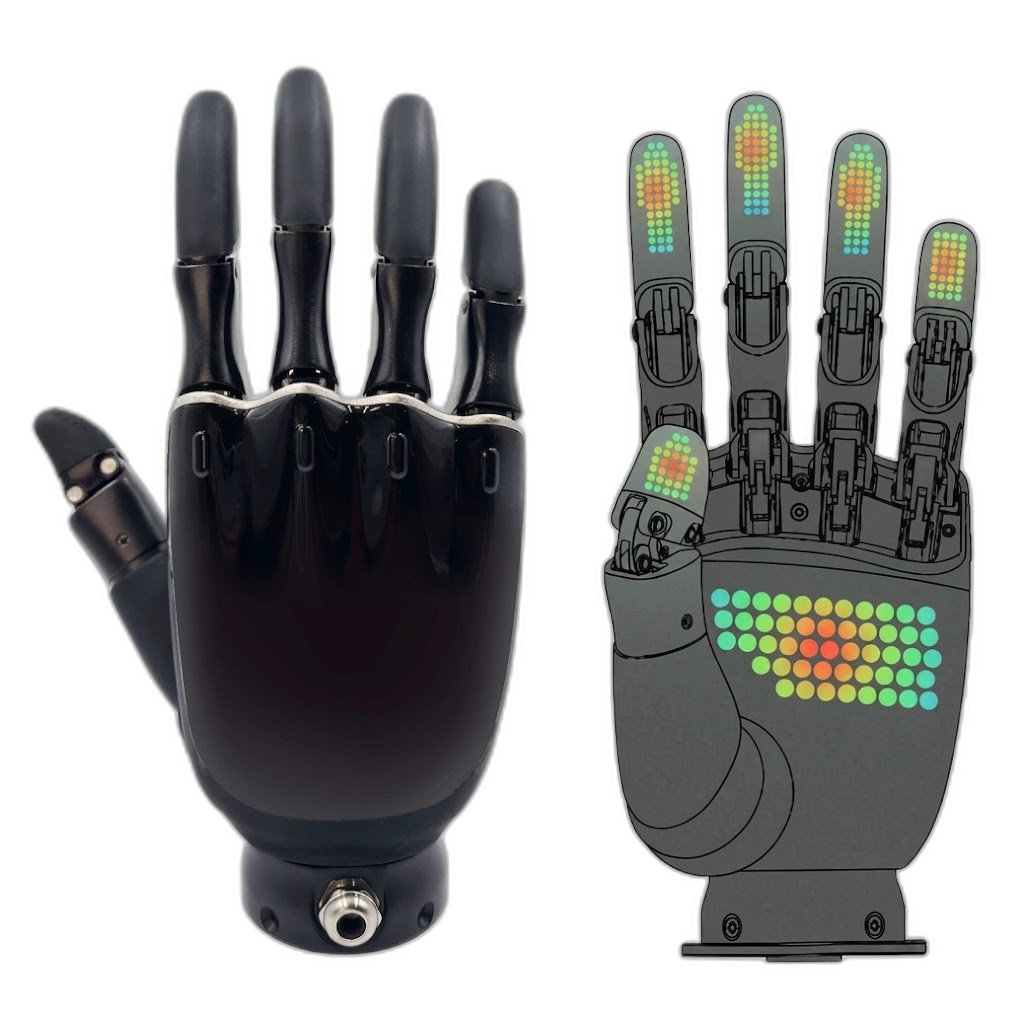
Experience optimized real-time force feedback and torque control with the integrated Tashan force sensor.
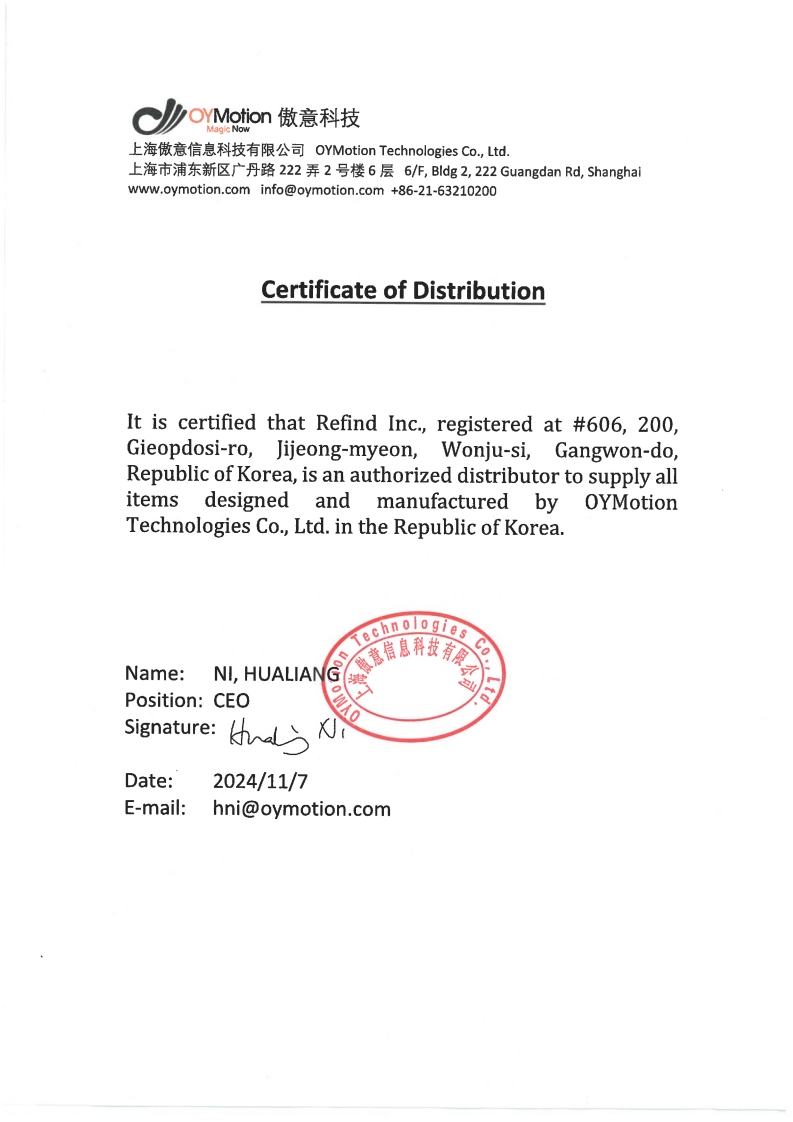
Authorized Distributor
OYMotion Technologies
Refind Inc. is the authorized distributor in South Korea for all products designed and manufactured by OYMotion Technologies Co., Ltd.
Features
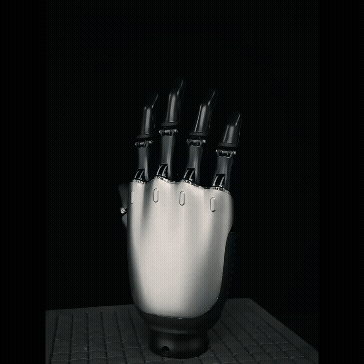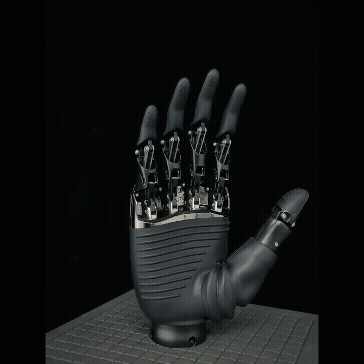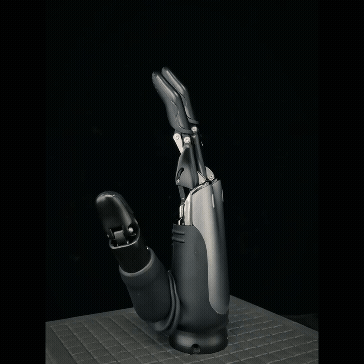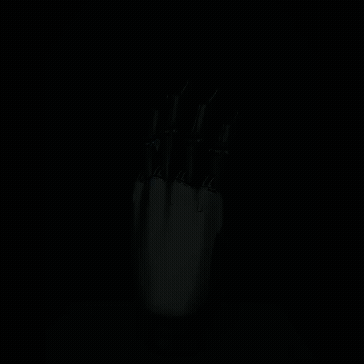
6-DOF mechanism embodying prosthetic hand expertise — perfectly replicates delicate human hand movements
Real-time remote control (mirroring) and teaching support via dedicated Data Glove integration
ROS/ROS2 packages and Python/C++ API for immediate R&D without complex setup
Standard RS-485 and Modbus interfaces for easy connection with various robot arms and PLCs
Derived from prosthetic hand technology, mimicking human hand movements and form
Product Video
ROH-AP001 in Action
Core Value
Integrated Force Sensing
Precise end-load measurement without external sensors for delicate force control
Bidirectional Feedback
Joint angle + force data fusion for high-quality robot path generation and learning
Industrial Reliability
Guaranteed measurement precision and durability under repeated force application
SDK Support
Dedicated Python and C++ libraries for instant deployment in research and process design
Technical Specs
Hardware Specs
Sensor & Interface
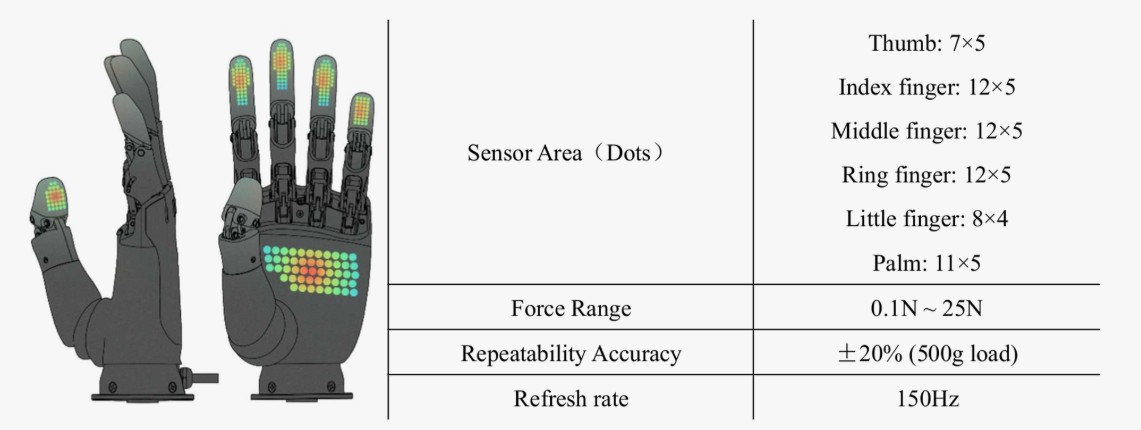
Sensor Specifications
Tashan Force Sensor Detail Specs
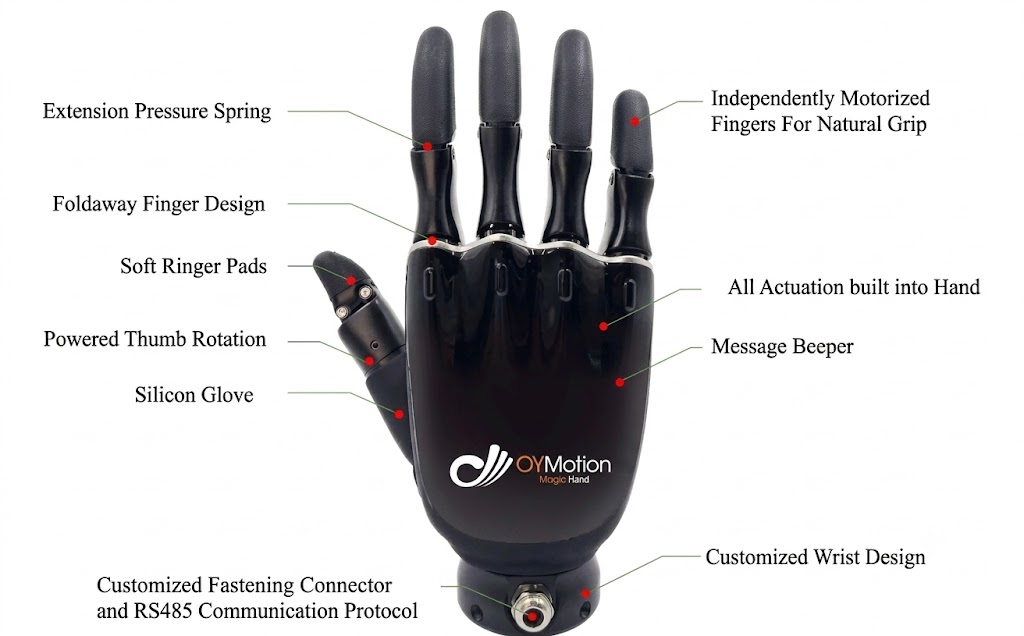
Product Structure
ROH-AP001 Structure Diagram
Size & Performance
ROH-AP001 Detailed Specifications
Weight: 661g ± 5g
Measurement
Performance
Use Cases
Precision Assembly
Real-time force detection during part assembly prevents damage and enables instant quality inspection
Surface Finishing
Automate sanding and polishing processes requiring constant pressure for uniform results
Medical/Bio Automation
Ideal for delicate bio-sample handling and force-feedback-based surgical robot research
Use Cases
Real-World Motion in Various Environments
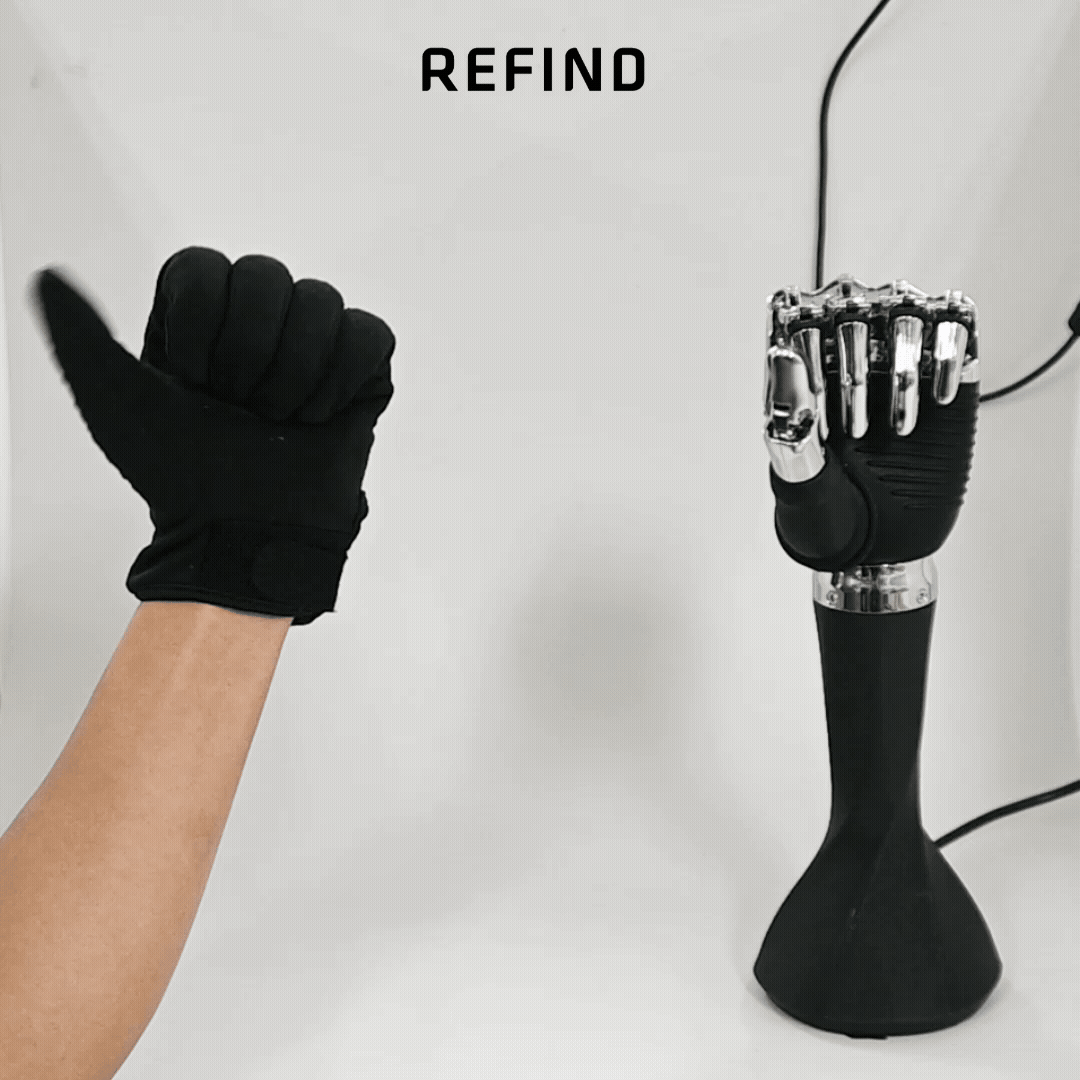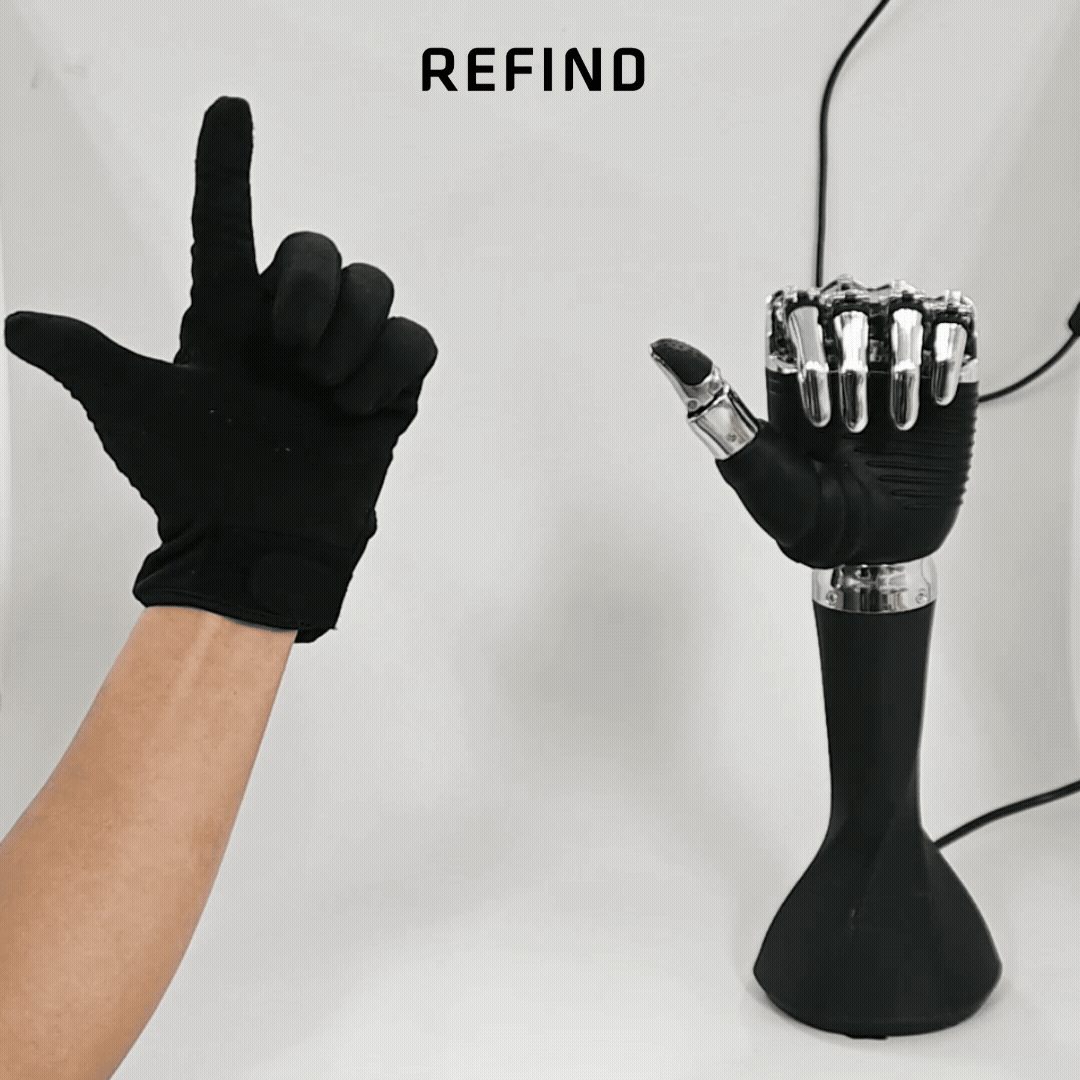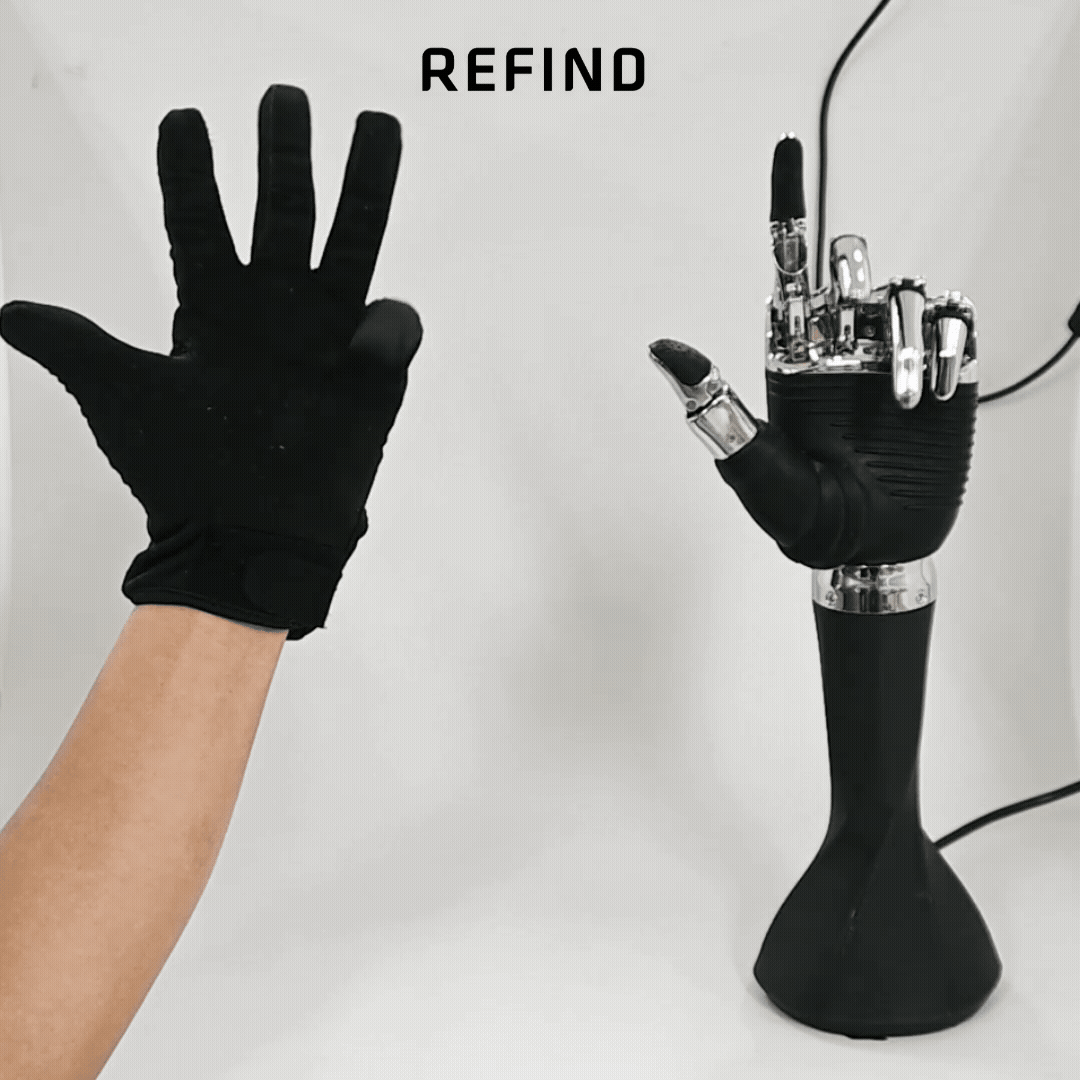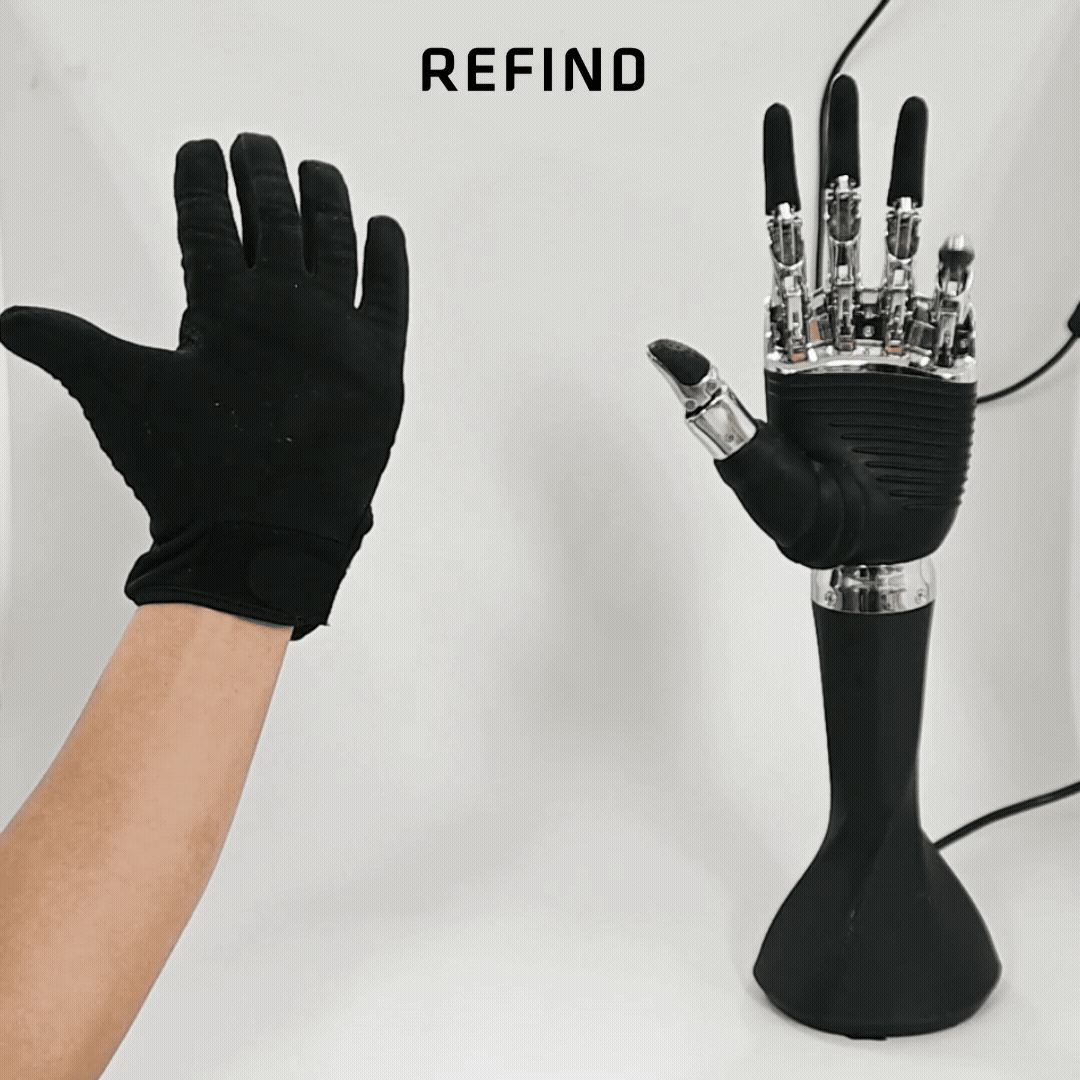 Basic Motion
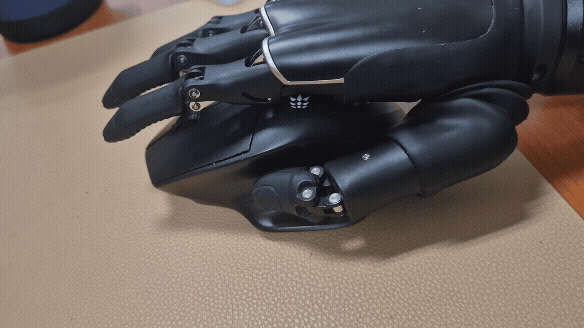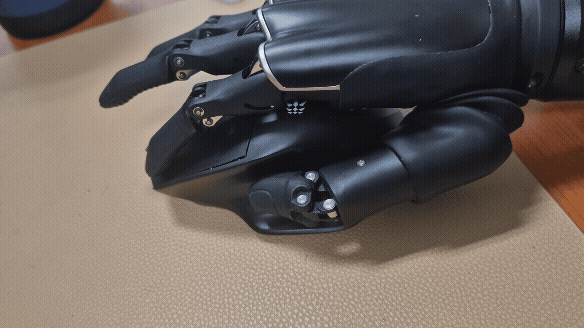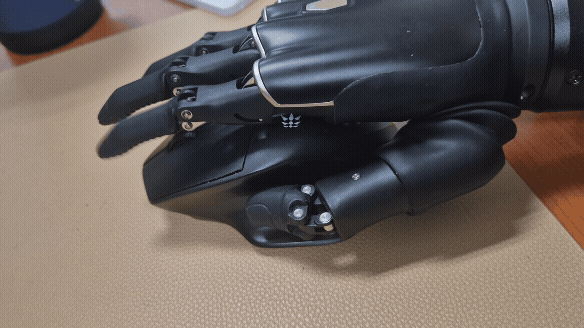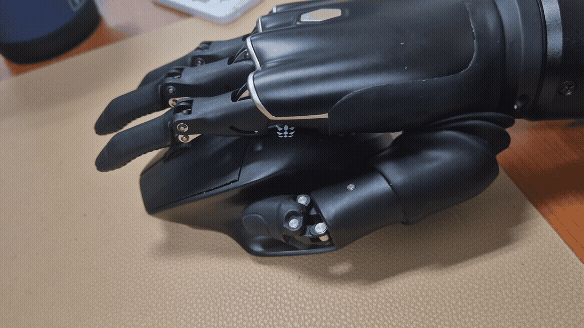 Click
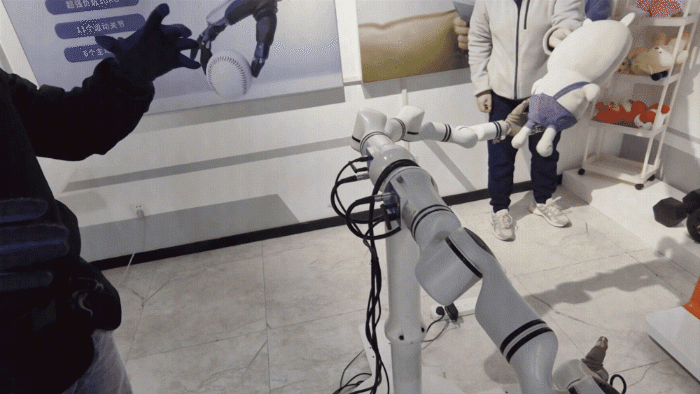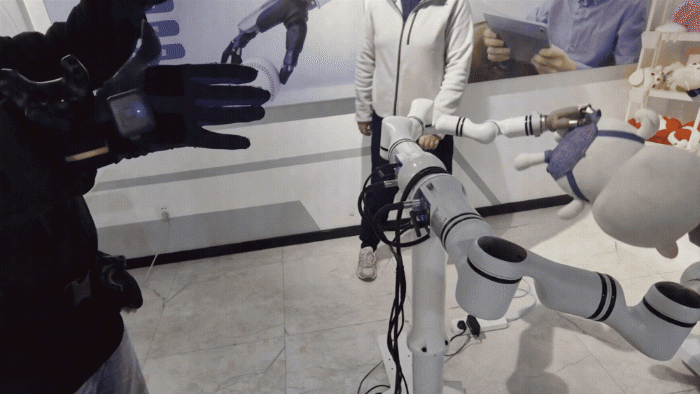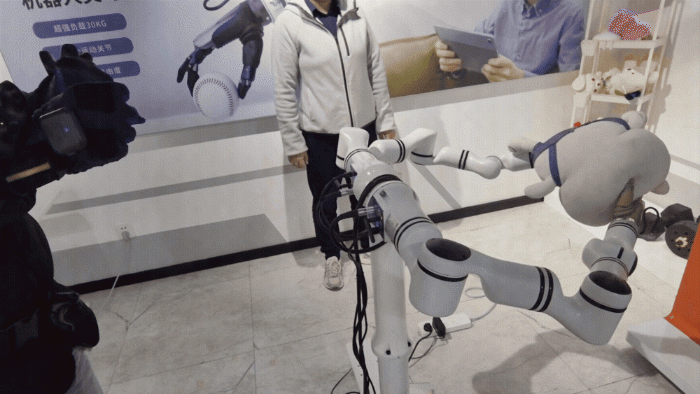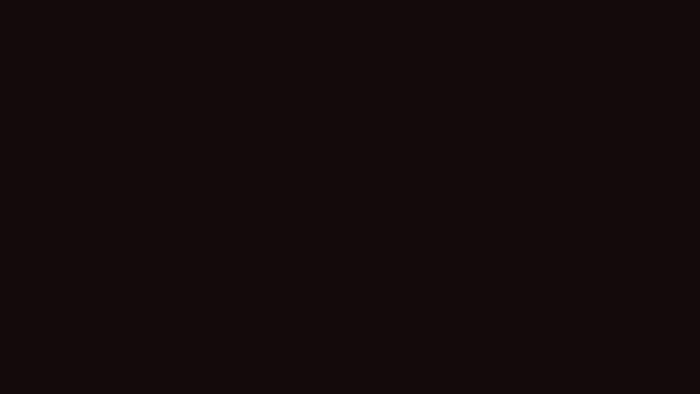 Grasping
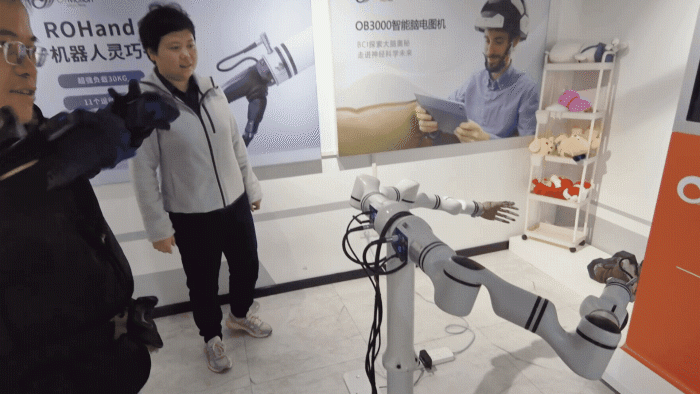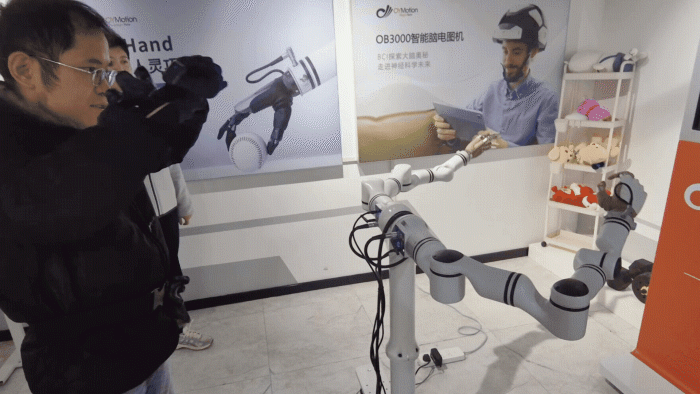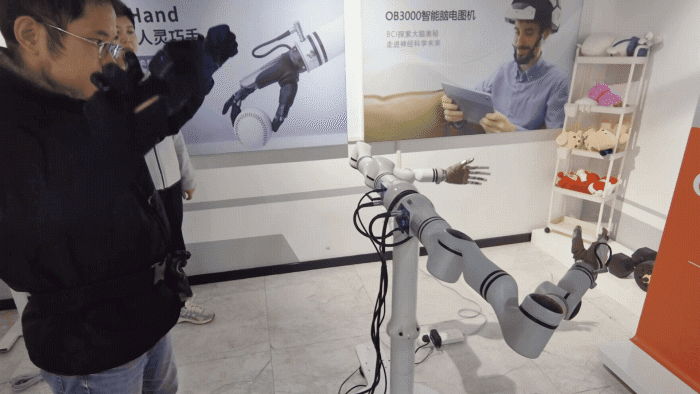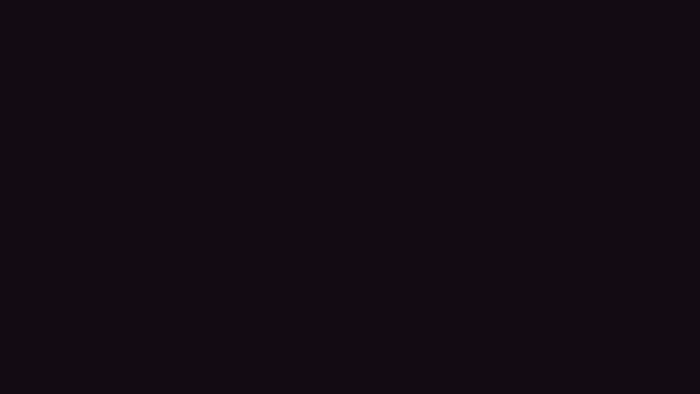 Movement
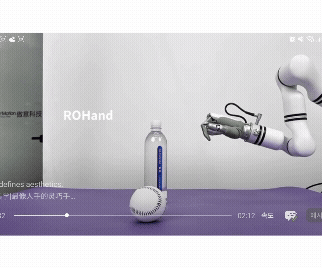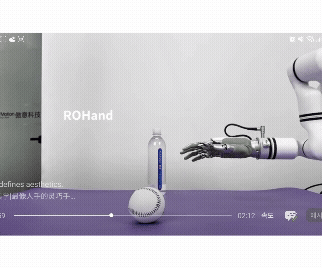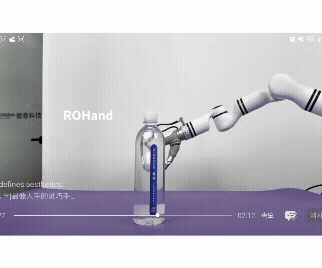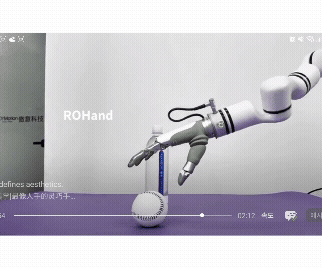 Gesture
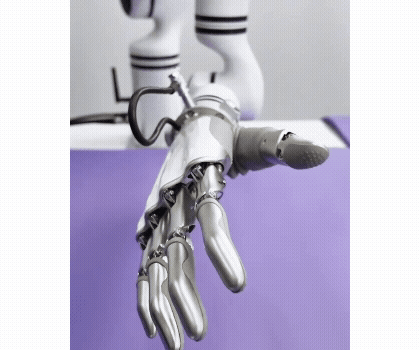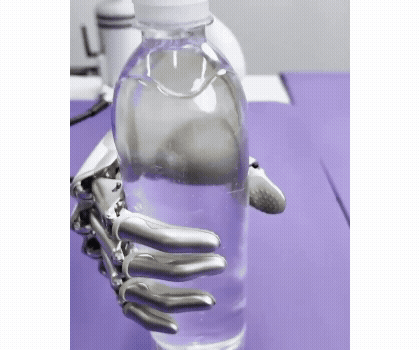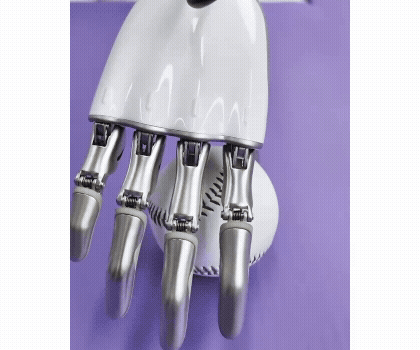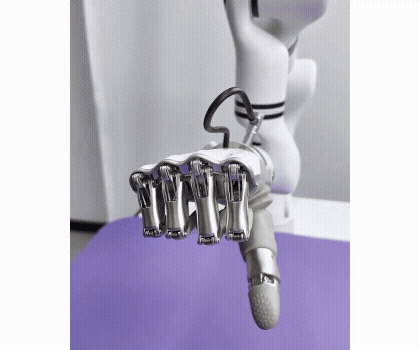 Gesture 2
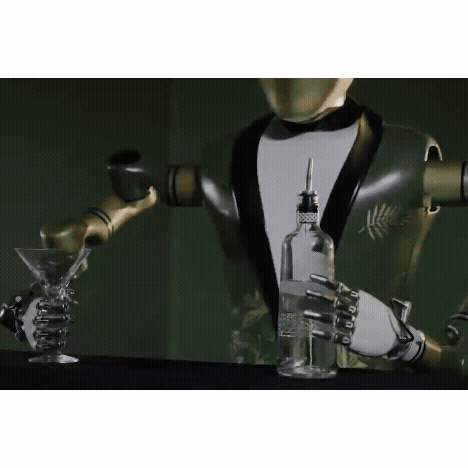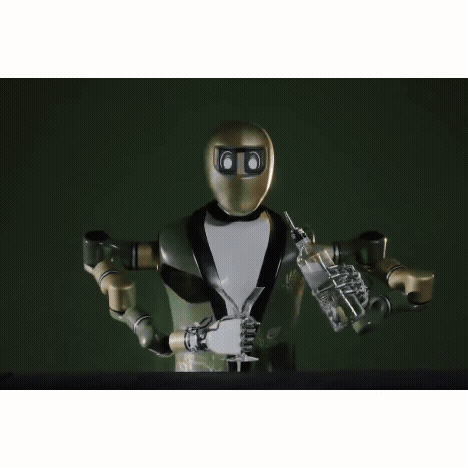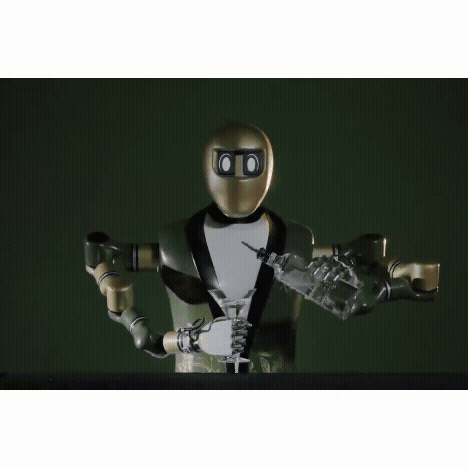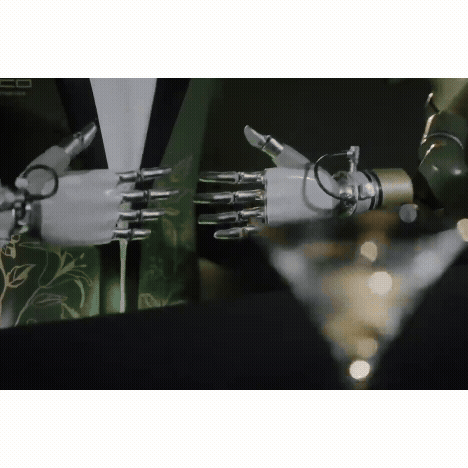 Humanoid
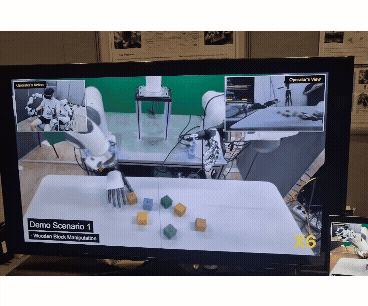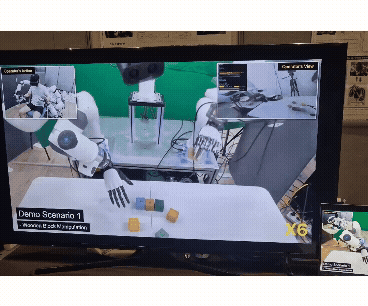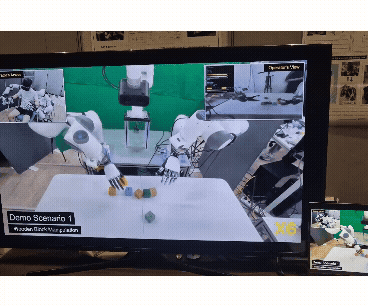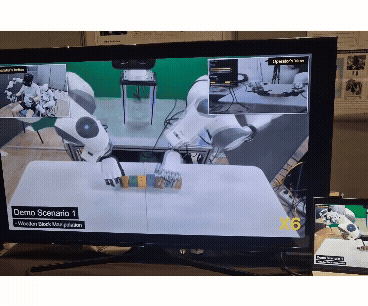 Robot Arm
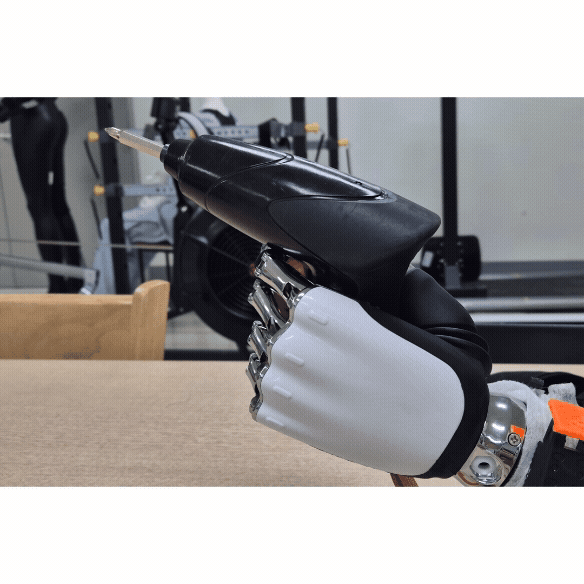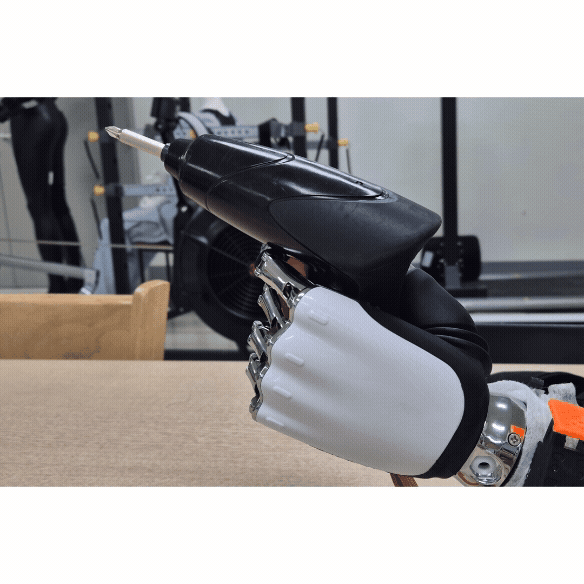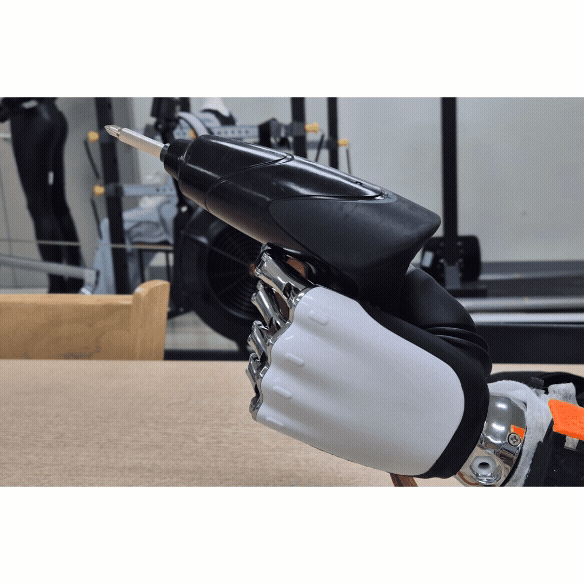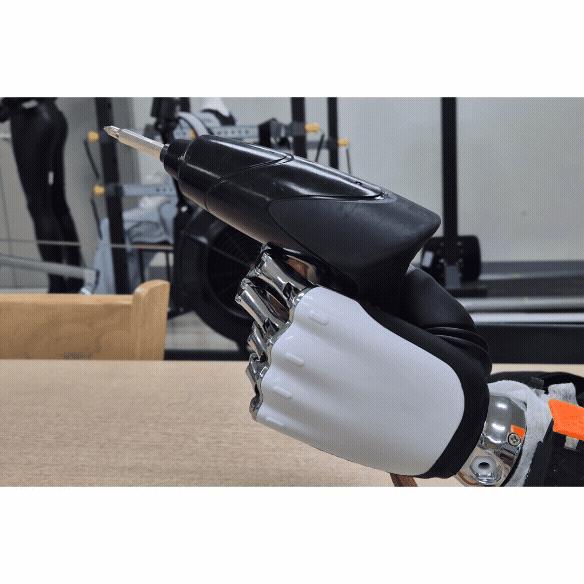
Precision Assembly
Real-time force detection during assembly prevents damage and enables instant quality inspection
Surface Finishing
Automate sanding and polishing requiring constant pressure for consistent, uniform results
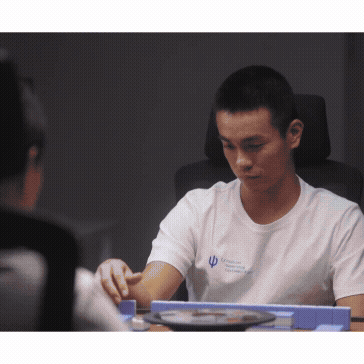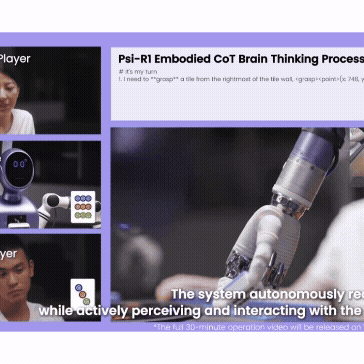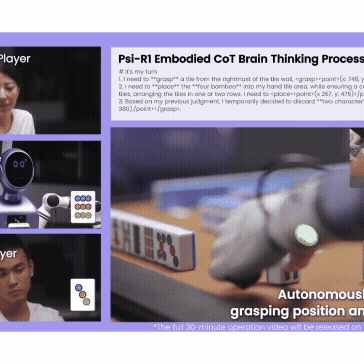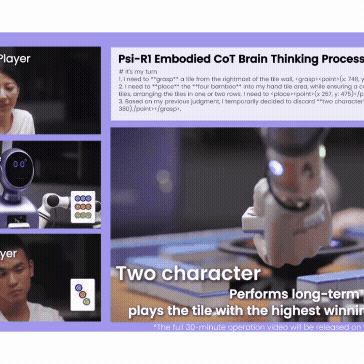
Medical / Bio Automation
Ideal for delicate bio-sample handling and force-feedback-based surgical robot research
Delivery Cases
Real-World Applications
Developer Resources
OYMotion Official Manual · SDK · Demos
User Manual
ROH-AP001 specifications and user guide
ViewSDK (C/C++, Python)
ROS/ROS2 packages and C++/Python API
ViewDemos (Gen2 · Sensor Models)
Sensor-focused demos for force/tactile sensor models (AP001, etc.)
ViewDemo Collection (All Models)
Combined demo set supporting both general and sensor models
ViewExperience the Innovation Firsthand
Refind goes beyond sales — we provide optimized technical support and custom solutions.
Contact Us