From approach to release
Capture proximity before contact and three-dimensional forces during interaction. Add physical contact information to visible hand movements.
TASHAN · WEARABLE TACTILE SENSING
Tactile data capture · Finger sleeves
Capture forces and proximity as people grasp and manipulate objects. Bring tactile data from real interactions into physical AI research.
3D Force
Three-dimensional forces
≥ 100 Hz
Sampling rate
< 100 g
Manufacturer-stated weight
≥ 4 h
Continuous acquisition
BEYOND MOTION
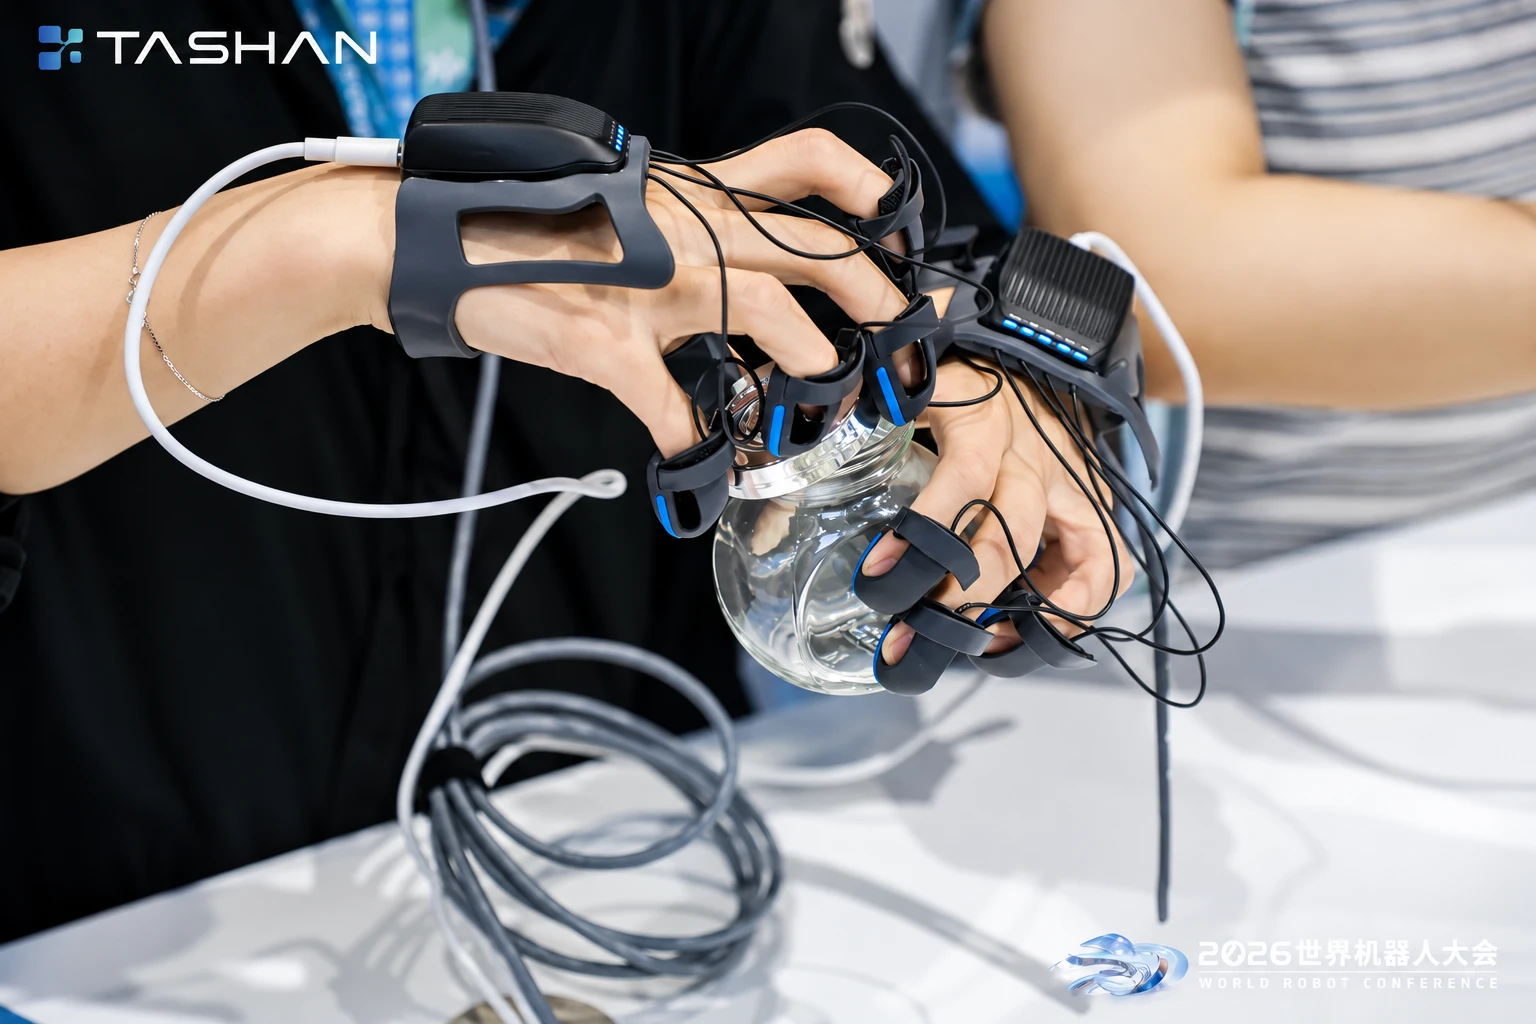
Video shows how a hand moves. TS-ECHO collects tactile information that helps identify when contact occurs and what forces act during that movement.
Capture proximity before contact and three-dimensional forces during interaction. Add physical contact information to visible hand movements.
Wear the system on a human hand to collect tactile data from everyday object manipulation without operating a robot for each demonstration.
The manufacturer describes time synchronization with vision and motion data, along with SDK integration. Build a capture setup around your cameras and recording system.
CAPTURE IN CONTEXT
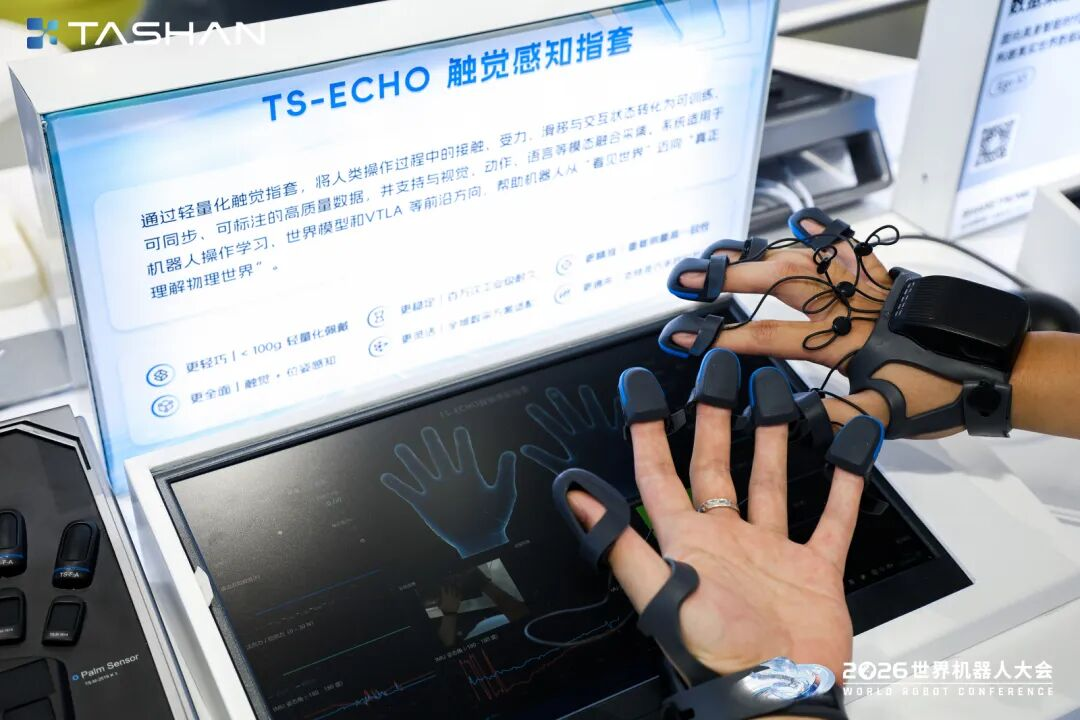
Fit the finger and wrist components and prepare your recording setup.
Perform the grasping and manipulation task with your own hands.
Record tactile signals and integrate relevant vision and motion data for analysis and learning.
APPLICATIONS
USE CASE / 01
Record contact during human grasping, transfer and release demonstrations for imitation-learning datasets.
USE CASE / 02
Support experiments on tactile-visual fusion, grasping strategies and human-object interaction.
USE CASE / 03
Build capture environments combining task videos and tactile signals. Confirm timing and data formats for your equipment.
SPECIFICATIONS
Based on the specification panel in TASHAN’s official WRC 2026 announcement, rather than a product manual. Confirm the supplied revision and measurement conditions when planning your project.
View original specification panel ↗FS means Full Scale. Confirm the components included in the stated weight, operating-time test conditions and SDK scope for your configuration.
Discuss one- or two-hand configurations, sensor count, connectivity, SDK, data formats and camera synchronization. Robot teleoperation and ROS 2 integration require a review of your intended system.
Source images and specifications: TASHAN. The hero photograph is AI retouched; refer to the linked original for product details. Application descriptions adapted by Refind.
START WITH YOUR RESEARCH
Tell us about your research and equipment so we can review a suitable configuration.