ROH-A002
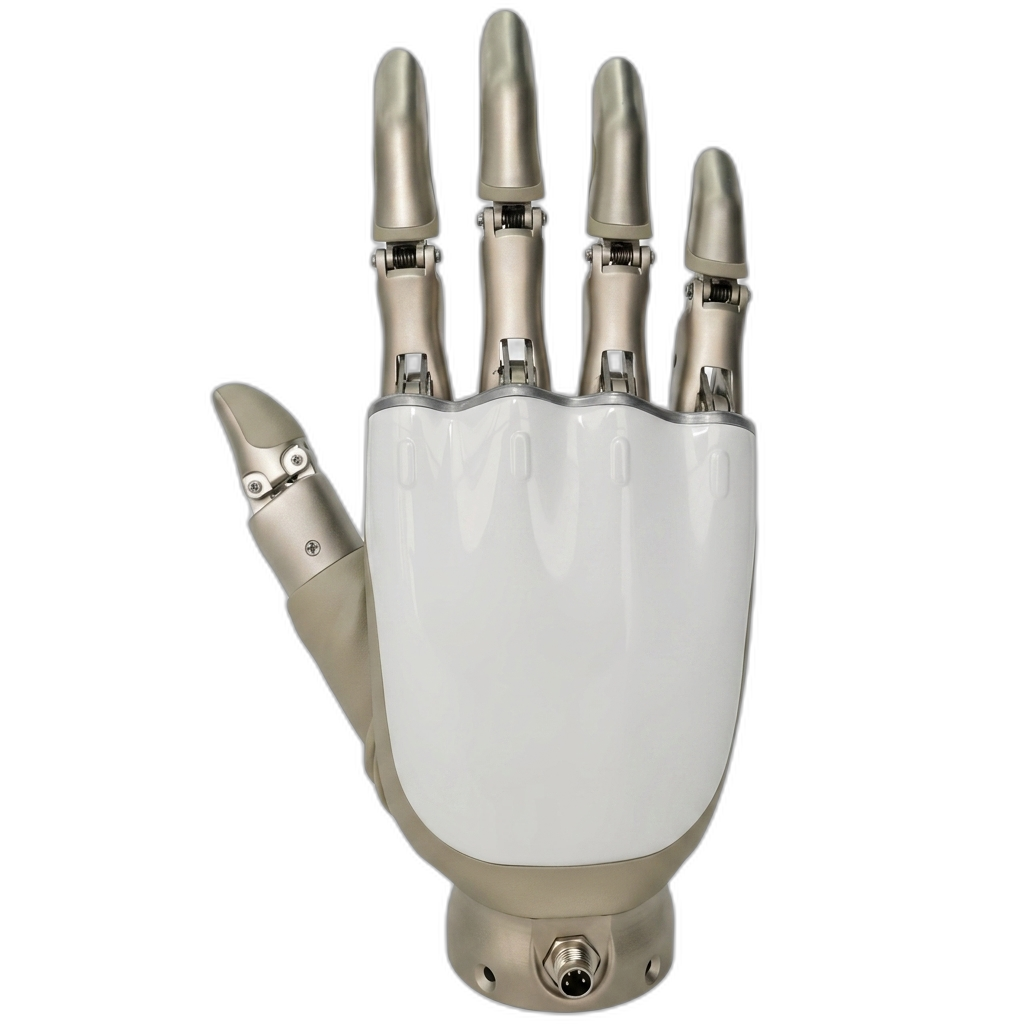
Pioneering new frontiers in robotic automation with a 6-DOF mechanism that perfectly replicates human hand motion.
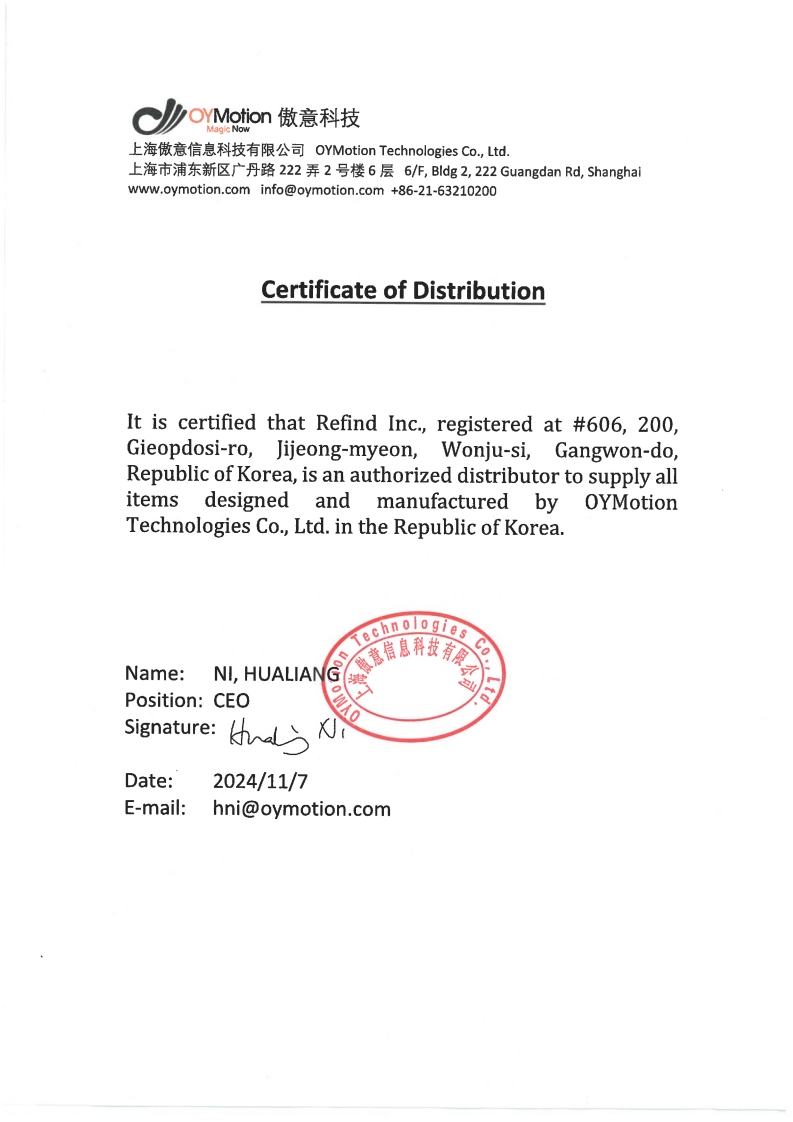
Authorized Distributor
OYMotion Technologies
Refind Inc. is the authorized distributor in South Korea for all products designed and manufactured by OYMotion Technologies Co., Ltd.
Features
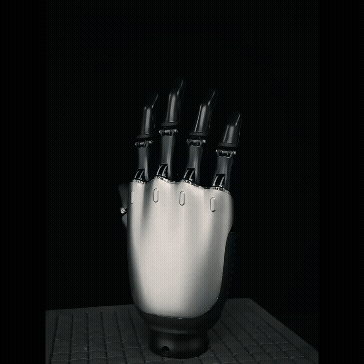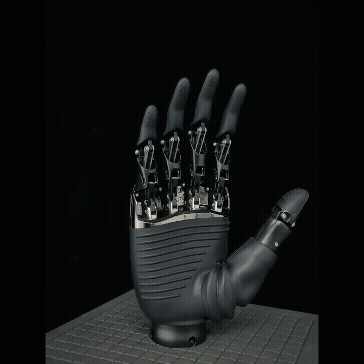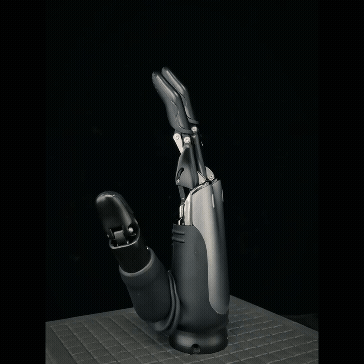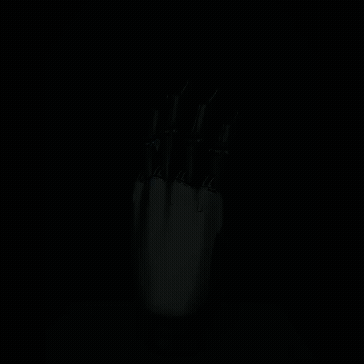
6-DOF mechanism embodying prosthetic hand expertise — perfectly replicates delicate human hand movements
Real-time remote control (mirroring) and teaching support via dedicated Data Glove integration
ROS/ROS2 packages and Python/C++ API for immediate R&D without complex setup
Standard RS-485 and Modbus interfaces for easy connection with various robot arms and PLCs
Derived from prosthetic hand technology, mimicking human hand movements and form
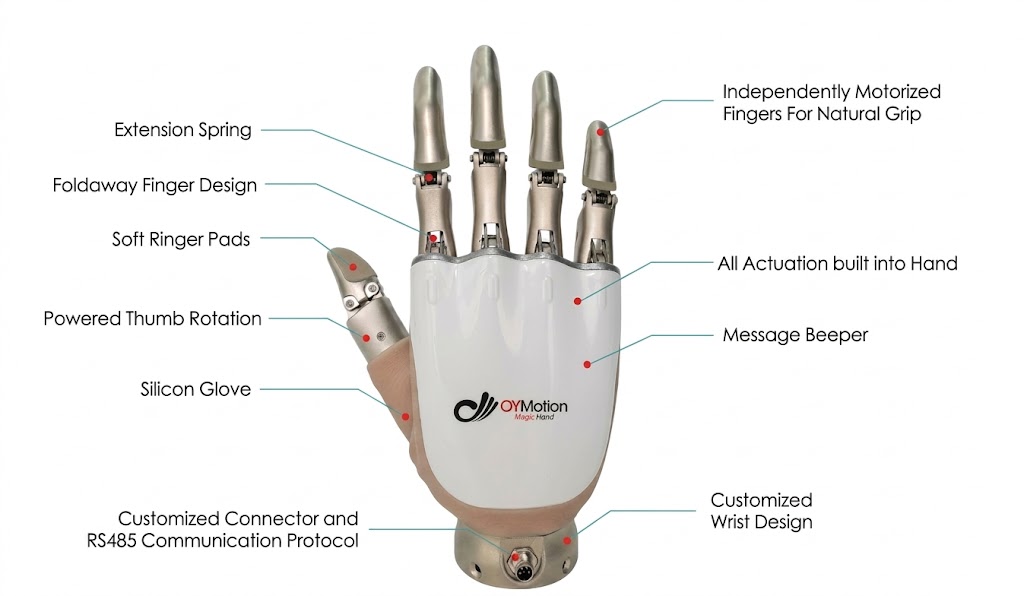
Product Structure
6-DOF Mechanism Structure
Dimensions
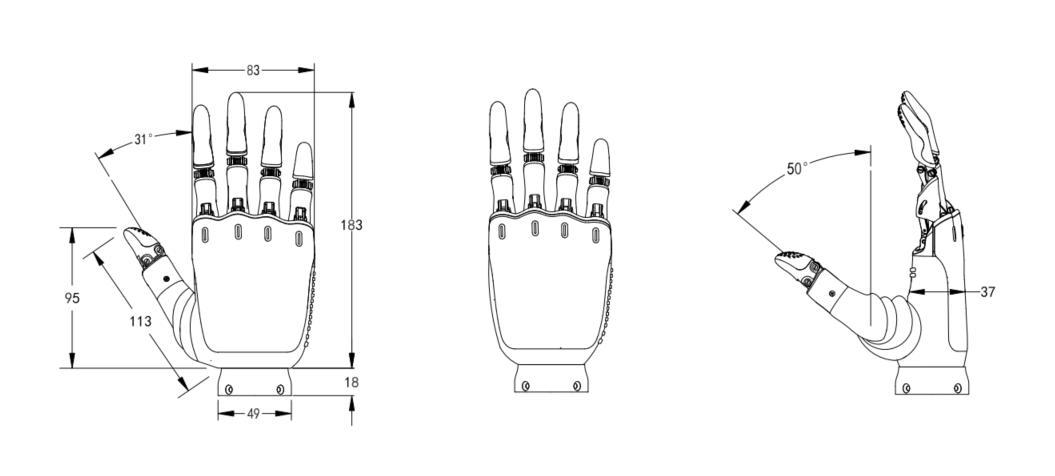
Product Dimensions
| Measurement Location | Dimensions and Angles |
|---|---|
| 중지 끝에서 손목까지 수직 거리Vertical distance from the tip of the middle finger to the wrist | 183 mm |
| 엄지 끝에서 손목까지 수직 거리Vertical distance from the thumb tip to wrist | 95 mm |
| 엄지 길이Thumb length | 113 mm |
| 최대 손바닥 너비Maximum palm width | 83 mm |
| 손목 직경Wrist diameter | 49 mm |
| 엄지 측면 최대 개폐 각도Maximum opening and closing angle of the thumb side | 0 ~ 31° |
| 엄지와 손바닥 최대 개폐 각도Maximum opening and closing angle of the thumb to the palm | 0 ~ 50° |
| 엄지 측면 회전 각도Thumb lateral rotation angle | 0 ~ 90° |
| 손가락 터치스크린 기능Finger touch screen function | Supported |
Specifications
| Measuring Position | Parameters |
|---|---|
| 완전 개방 → 완전 폐쇄 최소 시간Fastest time from fully open to fully closed finger | 0.7 s |
| 완전 폐쇄 → 완전 개방 최소 시간Fastest time from fully closed to fully open finger | 0.7 s |
| 엄지 측면 및 반대 손바닥 회전 최소 시간Fastest time from thumb side and opposite palm rotation | 0.7 s |
| 신전 상태 각 손가락 끝 능동력Active force per fingertip (stretched) | ≥ 0.5 kgf |
| 엄지 끝 최대 능동 추력Maximum active thrust force of thumb tip | ≥ 1 kgf |
| 굴곡 상태 각 손가락 끝 능동력Active force per fingertip (bent) | ≥ 1 kgf |
| 네 손가락 굴곡 상태 최대 수동 하중Maximum passive load for four fingers (bent) | 30 kg |
| 단일 손가락 최대 정적 하중 (파워그립)Maximum single finger static load (power grip) | 10 kg |
| 단일 손가락 끝 최대 정적 하중 (평면 신장)Maximum static load on fingertip of single finger (flat extension) | 8 kg |
Core Value
Precision Engineering
6-DOF human-like structure enabling perfect grasping of irregular objects
High Payload
Supports a maximum passive load of 30kg with four fingers bent
Seamless Integration
Open SDK based on ROS2, Python, C++ for instant integration with any robot platform
Technical Specs
1Mechanism
2Interface
Download
ROH-A002 Official Manual
PDF · V1.1.5
Use Cases
Real-World Motion in Various Environments
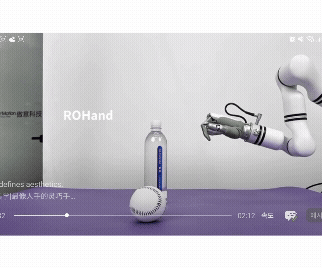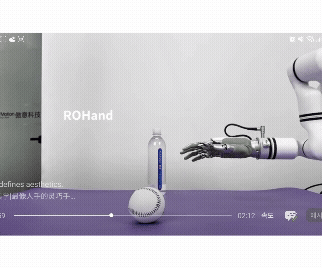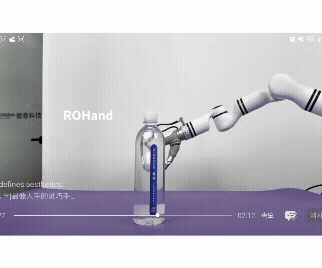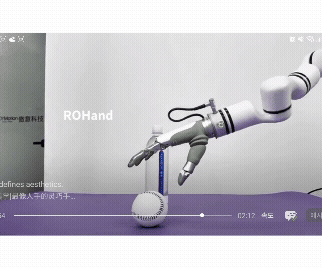
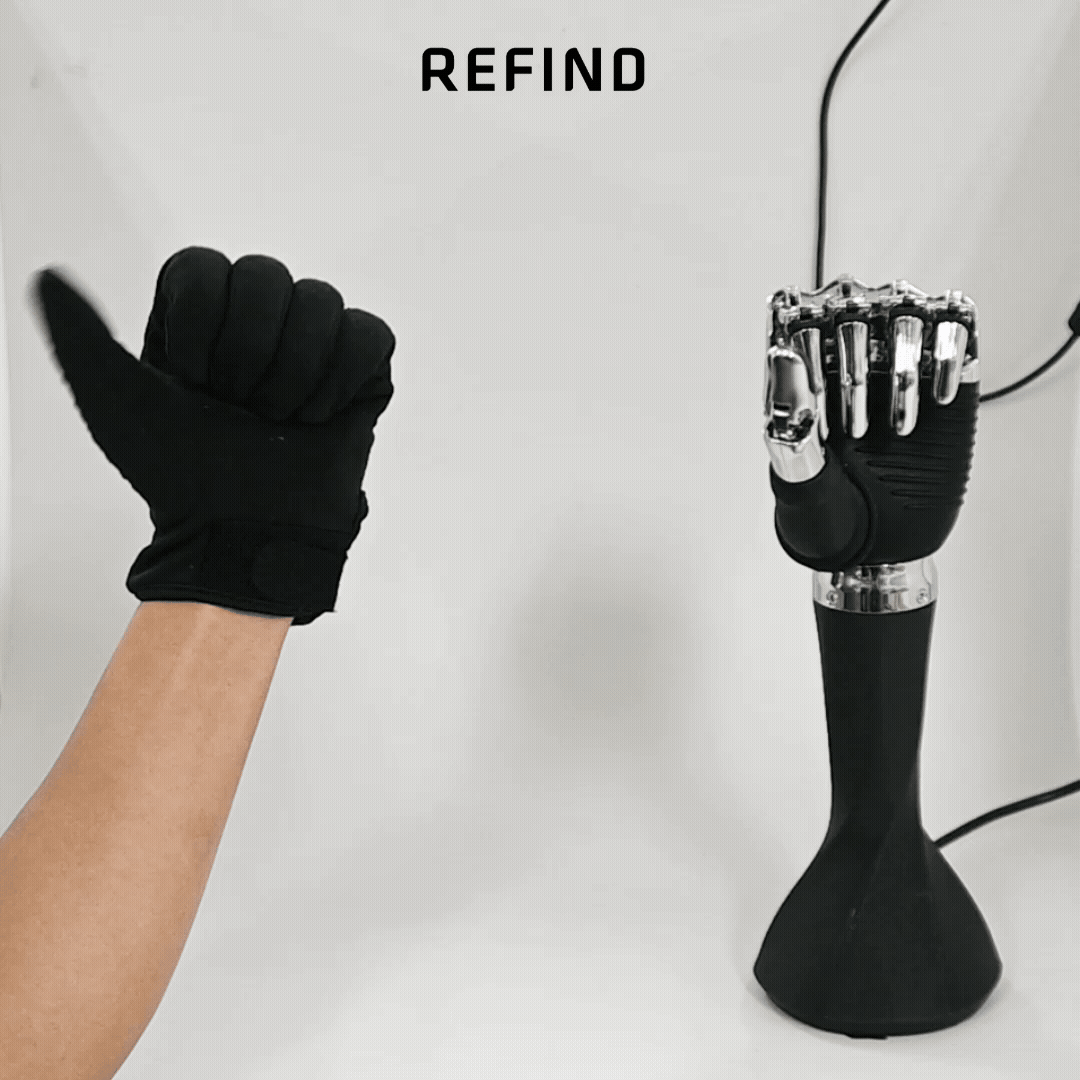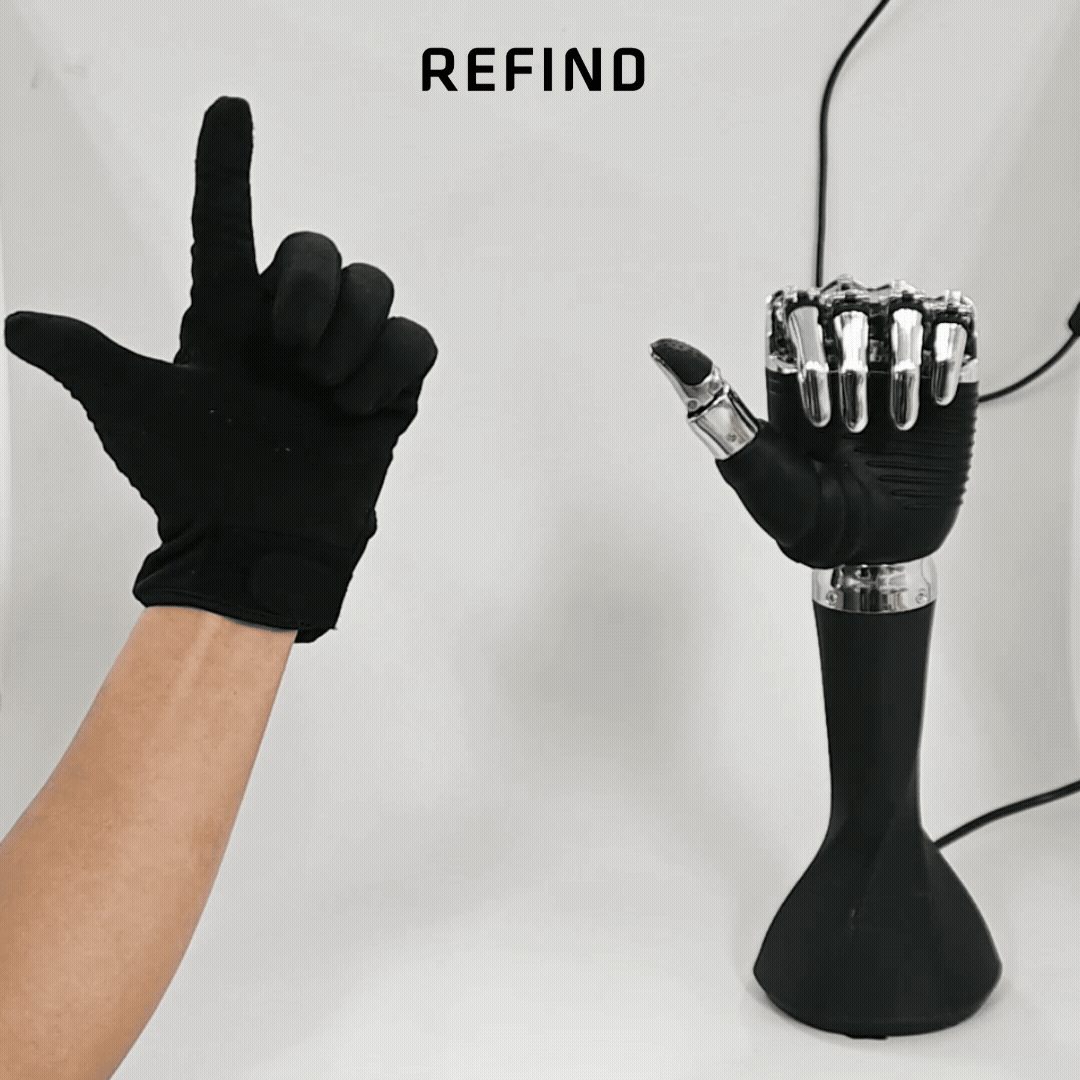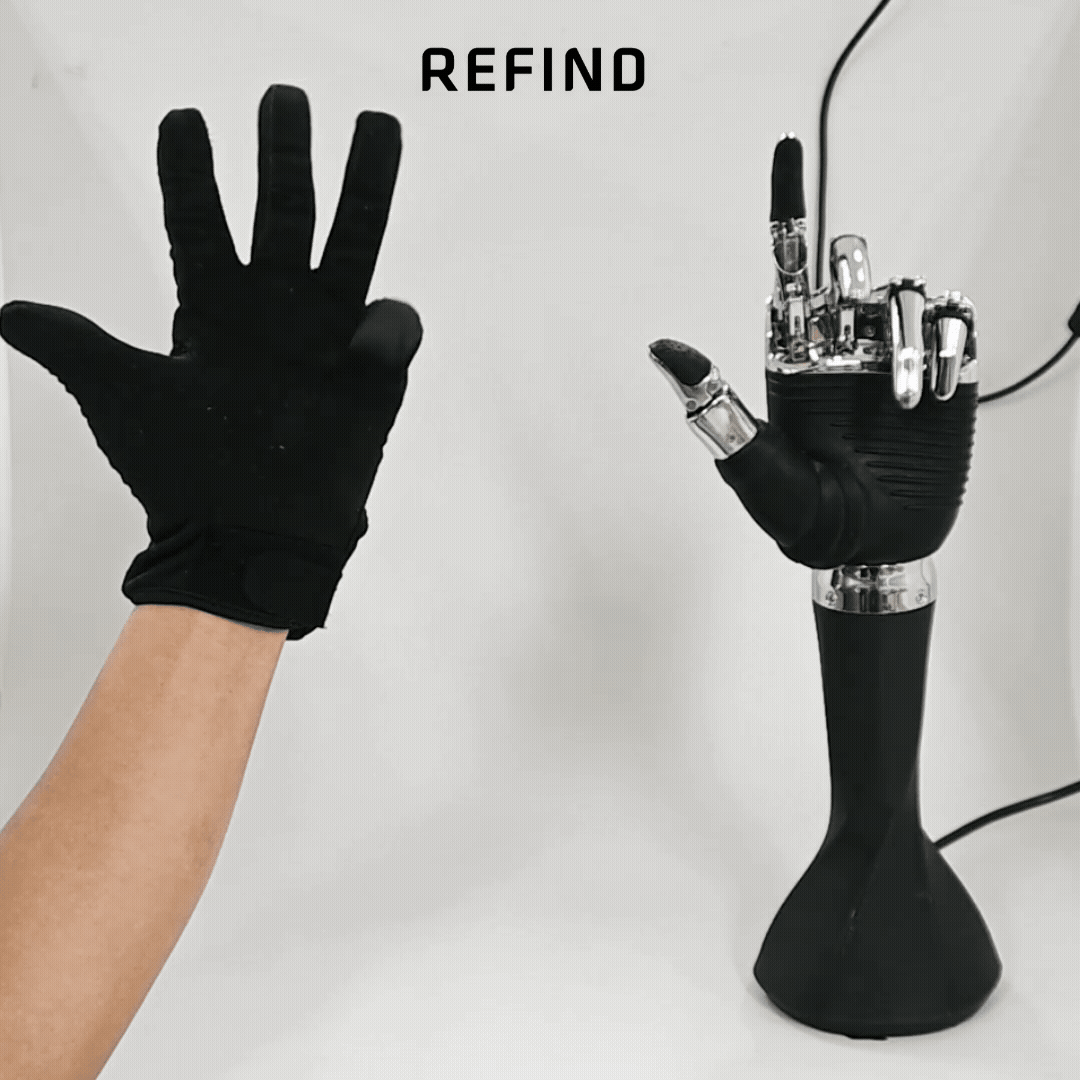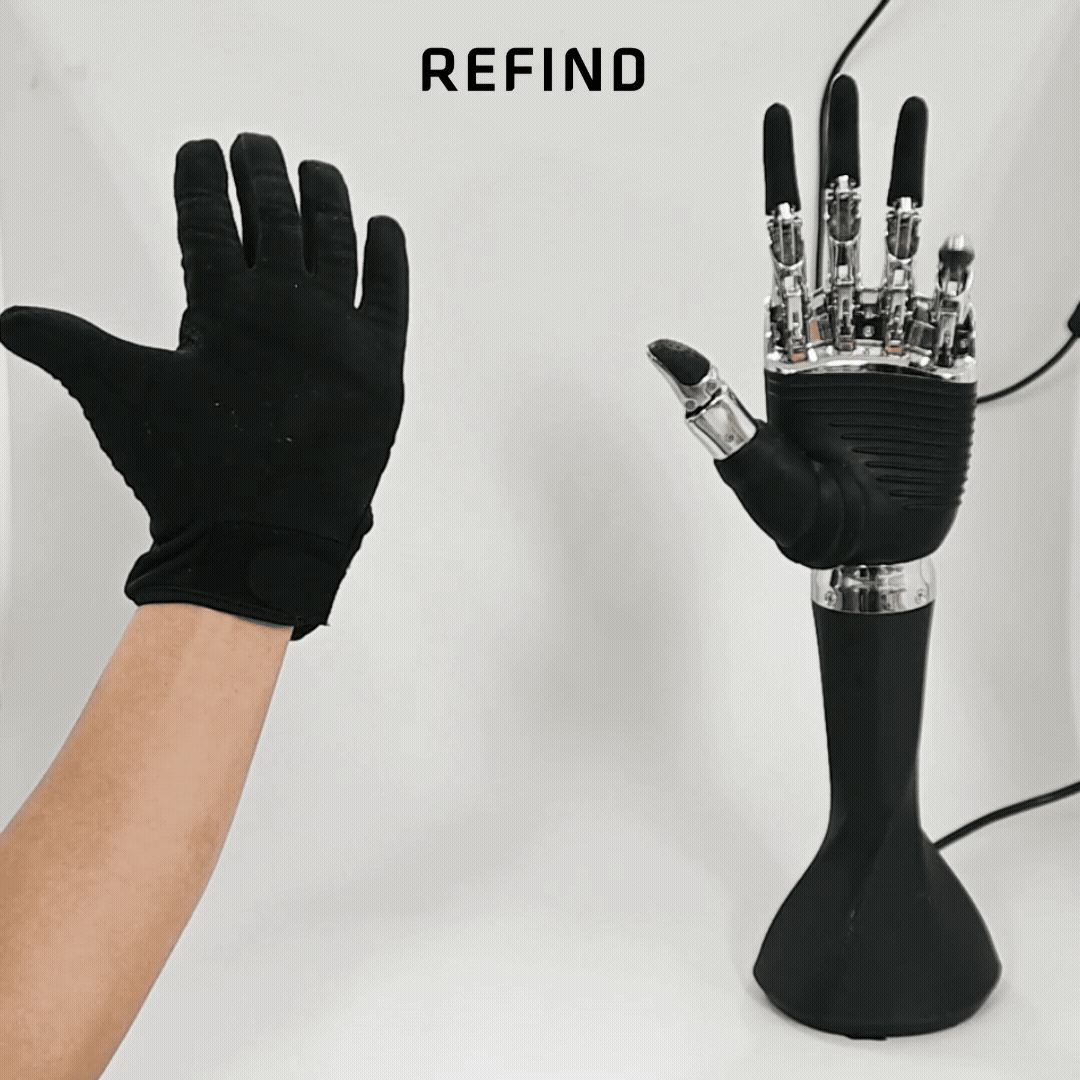 Basic Motion
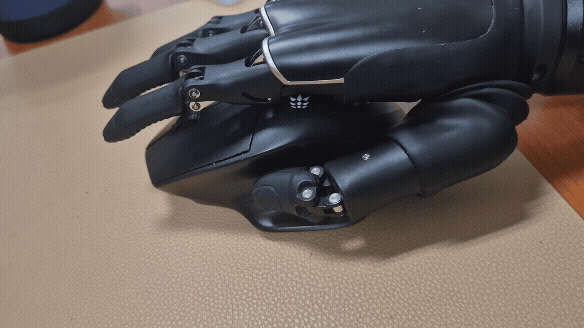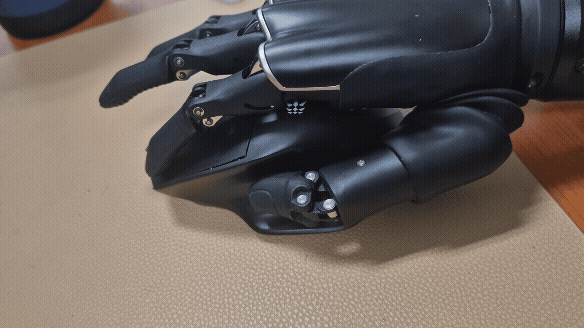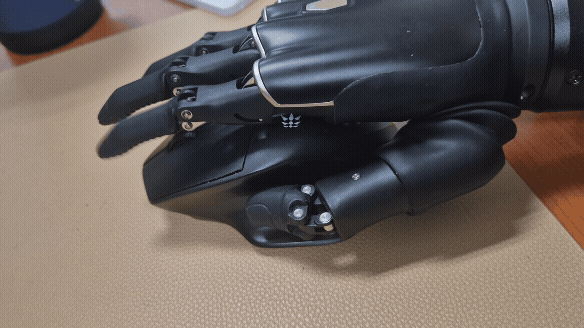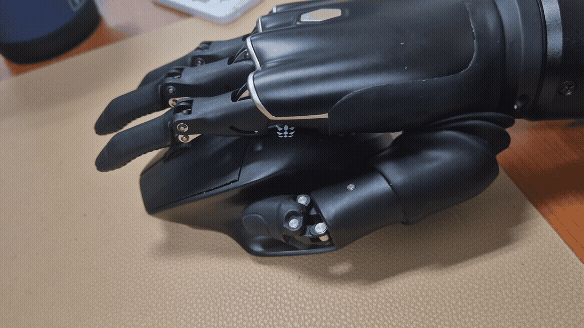 Click
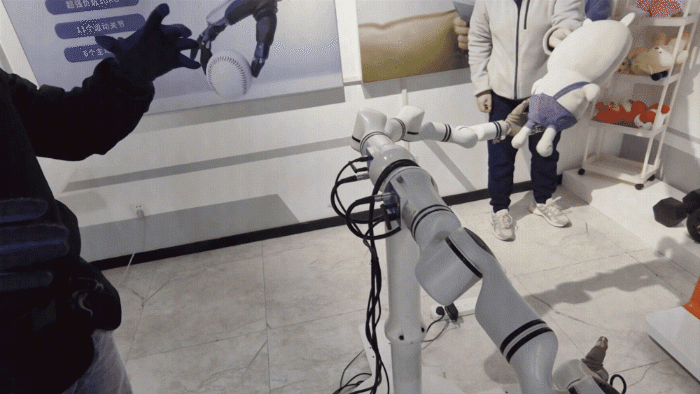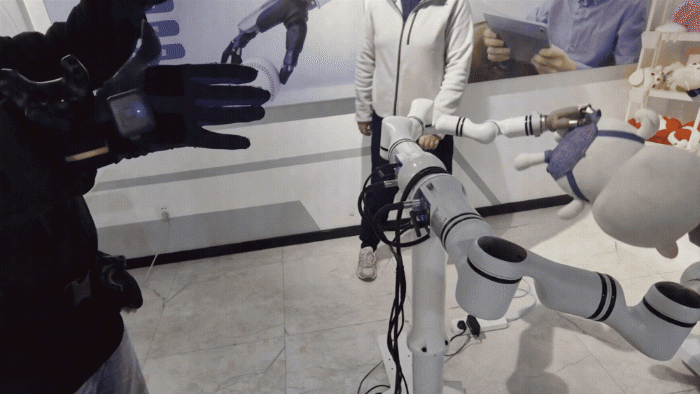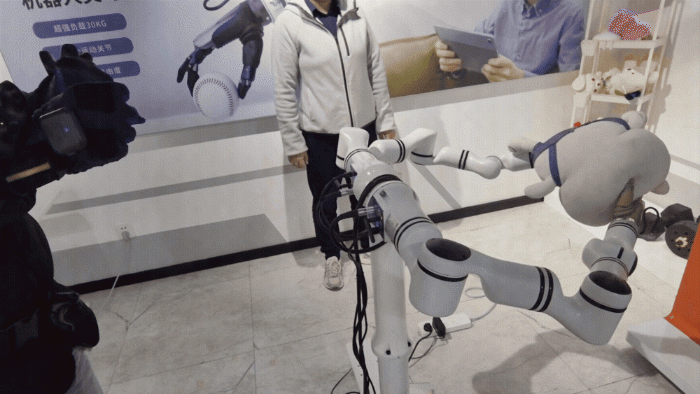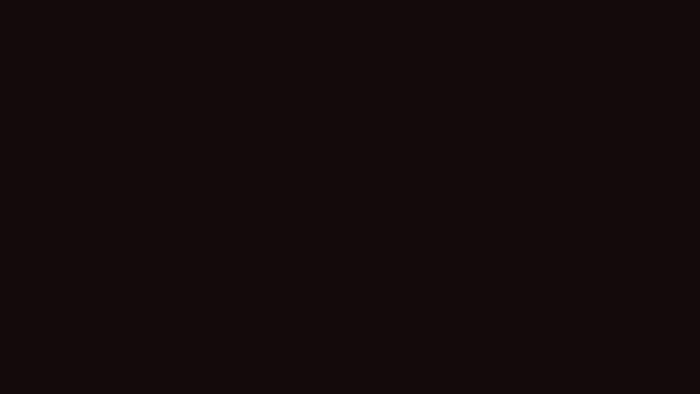 Grasping
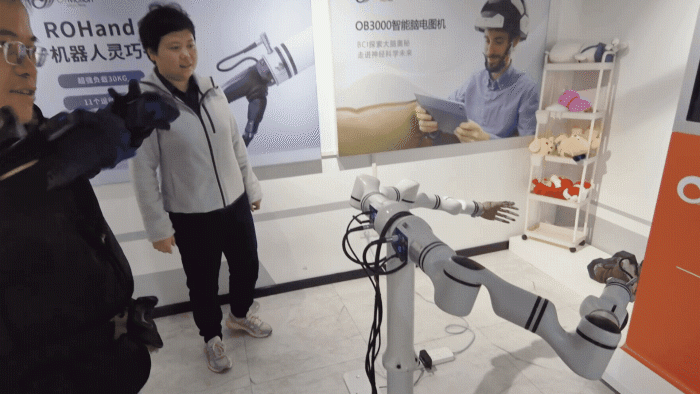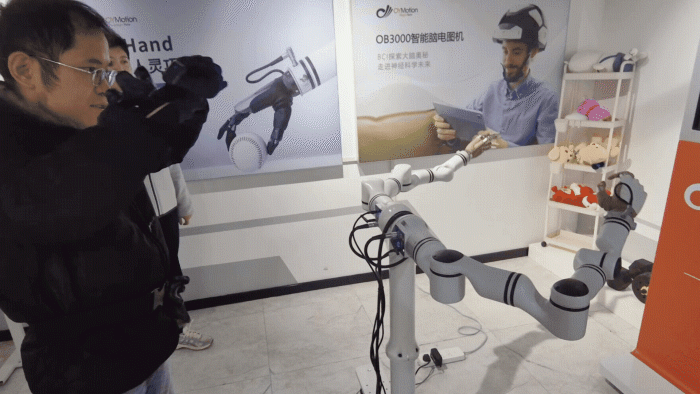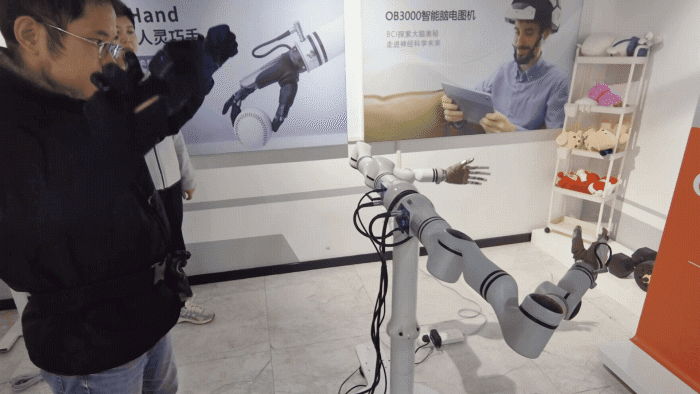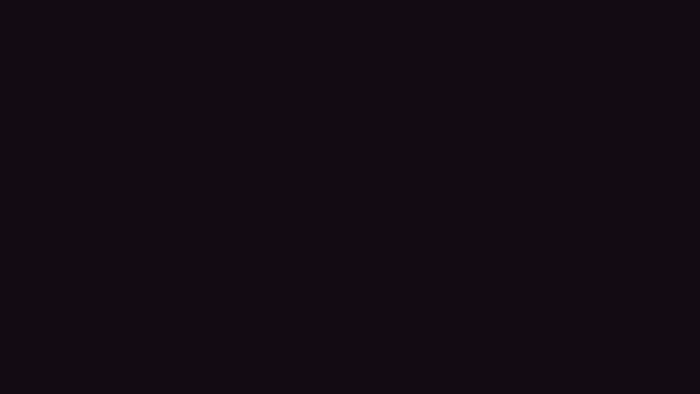 Movement
 Gesture
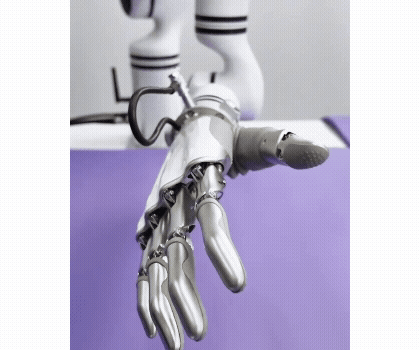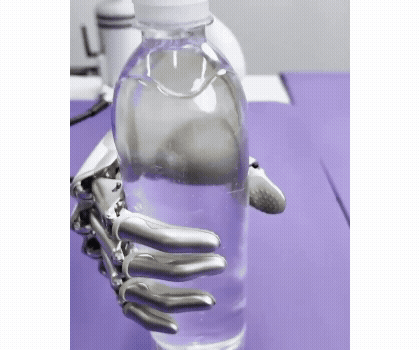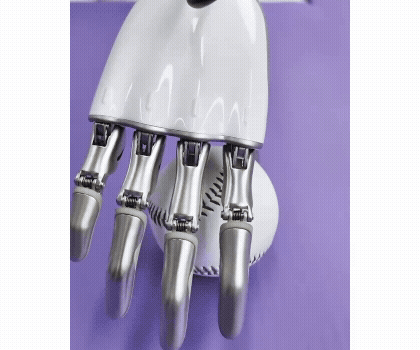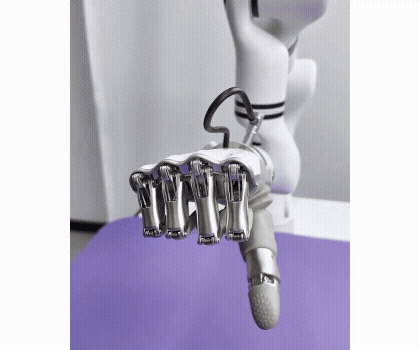 Gesture 2
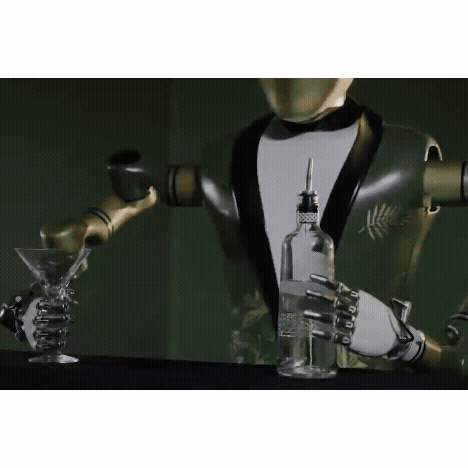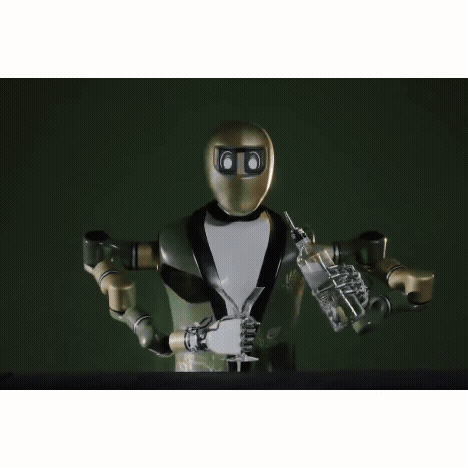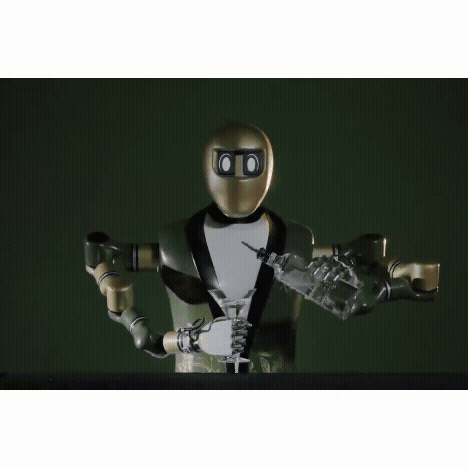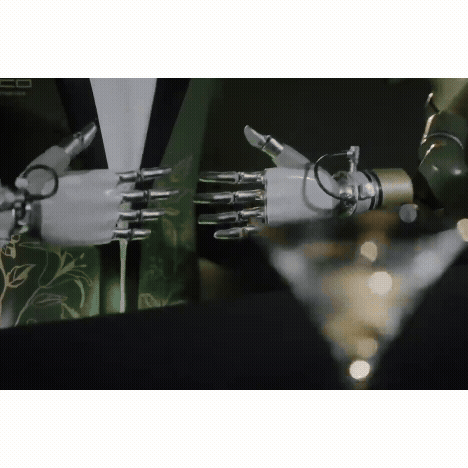 Humanoid
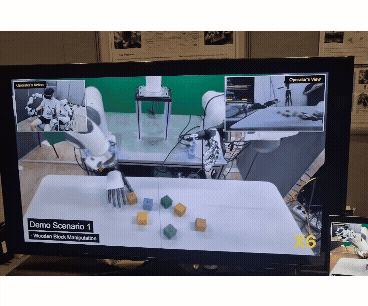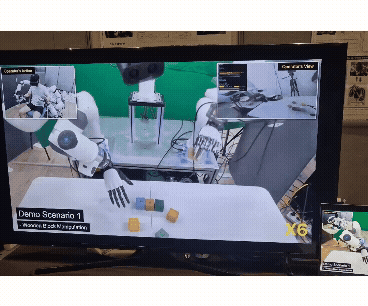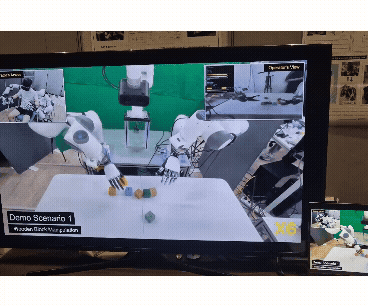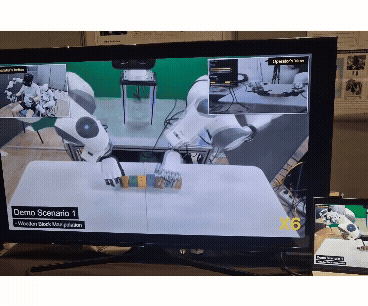 Robot Arm
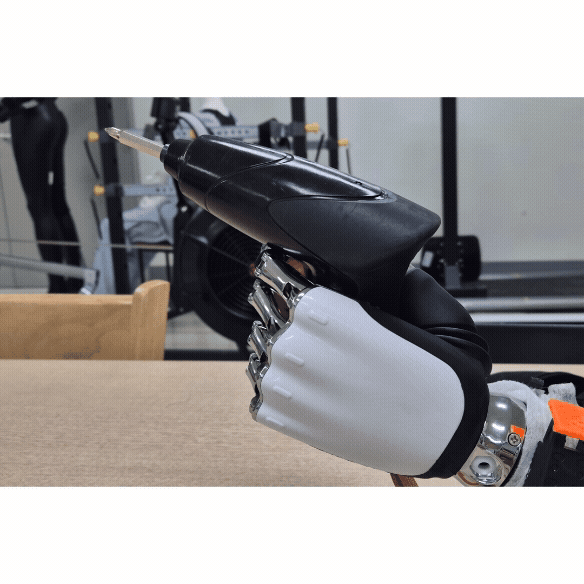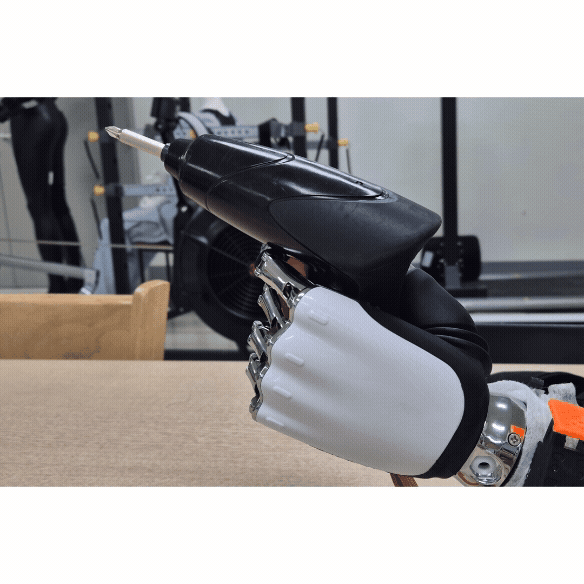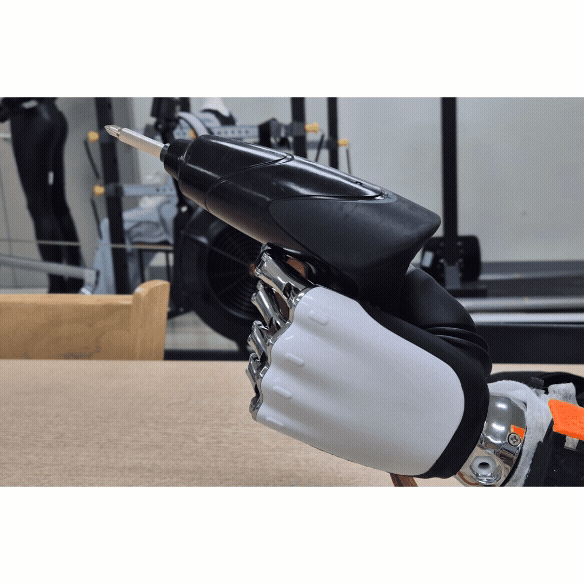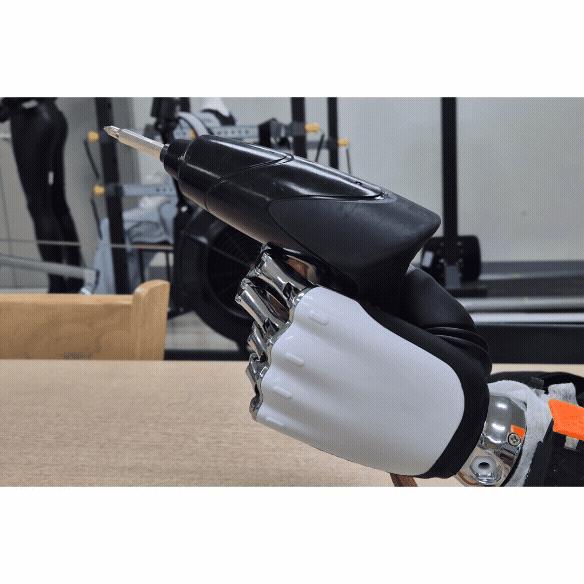
Lab / University AI
Maximize research output through grasping algorithm research and high-precision data collection
Humanoid Manufacturing
Secure human-level task performance capability as a next-gen robot interface
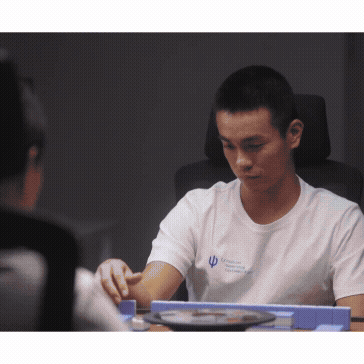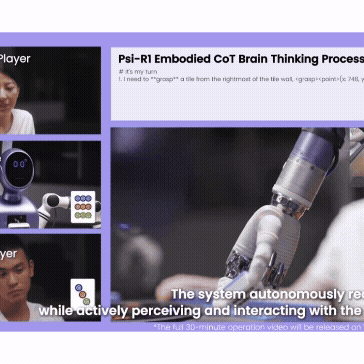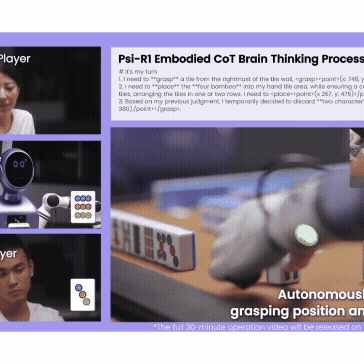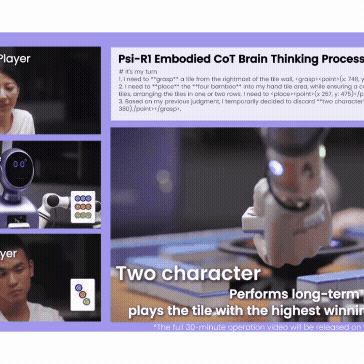
Smart Factory
Expand irregular object picking and process automation scope, reduce defect rates
Model Comparison
Choose the optimal robot hand model for your application.
| Spec | ROH-A002 | ROH-AP001 | ROH-AP002 | ROH-Lite |
|---|---|---|---|---|
| Movable Joints / Active DOF | 11 / 6 DOF | 11 / 6 DOF | 11 / 6 DOF | 11 / 6 DOF |
| Weight | 580g | 661g | 626g ± 5g | 486g |
| Speed | 0.7초 | 0.7초 | 0.7초 | 0.7초 |
| Force/Tactile | None | Tashan 포스 | 3D 포스+팜 | None |
| Comm. | UART/RS485/CAN | UART/RS485/CAN | UART/RS485/CAN | UART/RS485/CAN |
Delivery Cases
Real-World Applications
Developer Resources
OYMotion Official Manual · SDK · Demos
Experience the Innovation Firsthand
Refind goes beyond sales — we provide optimized technical support and custom solutions.
Contact Us